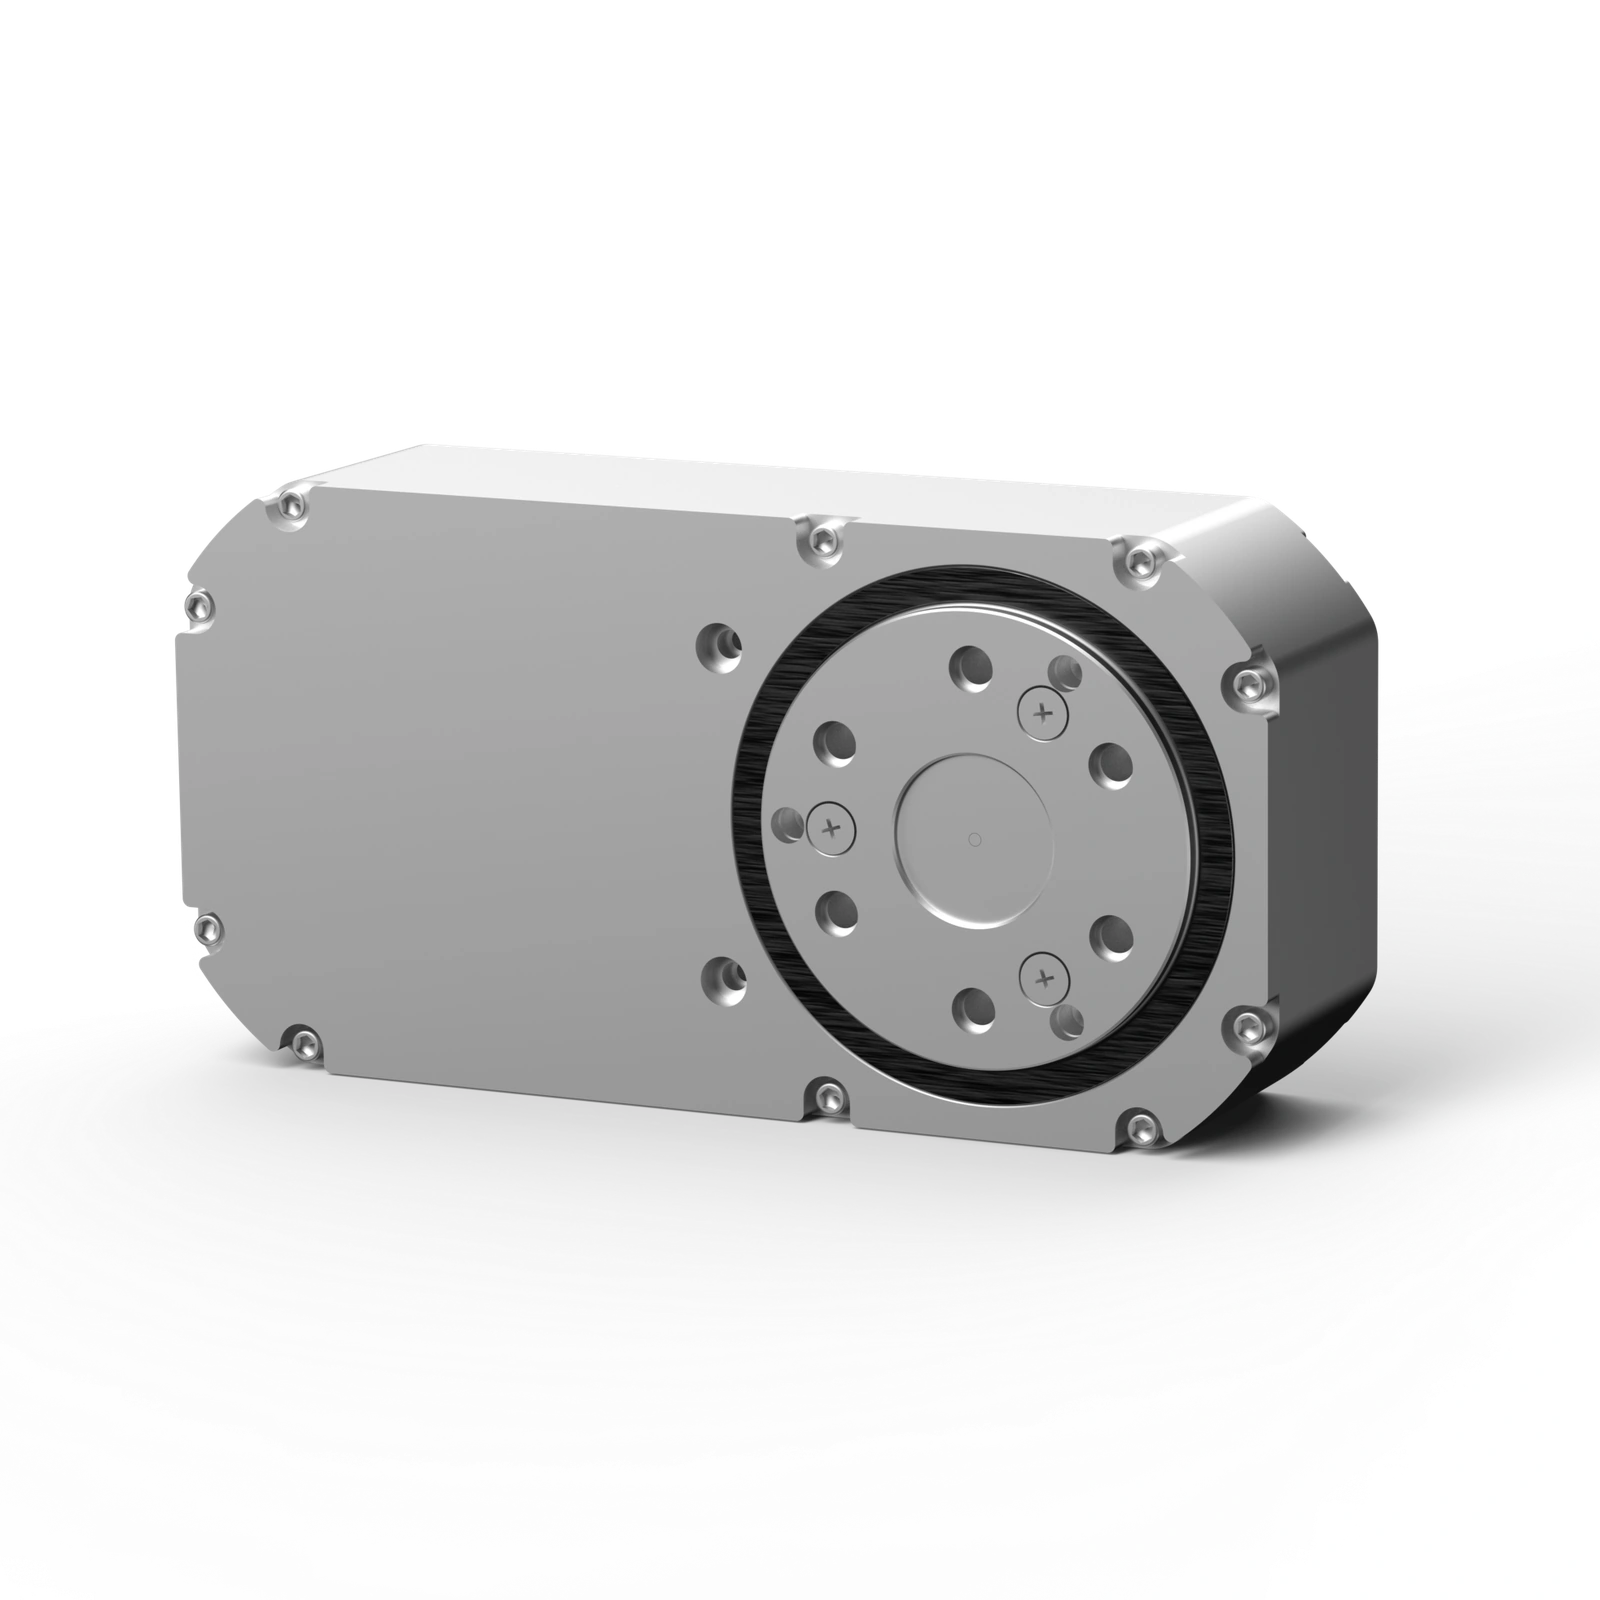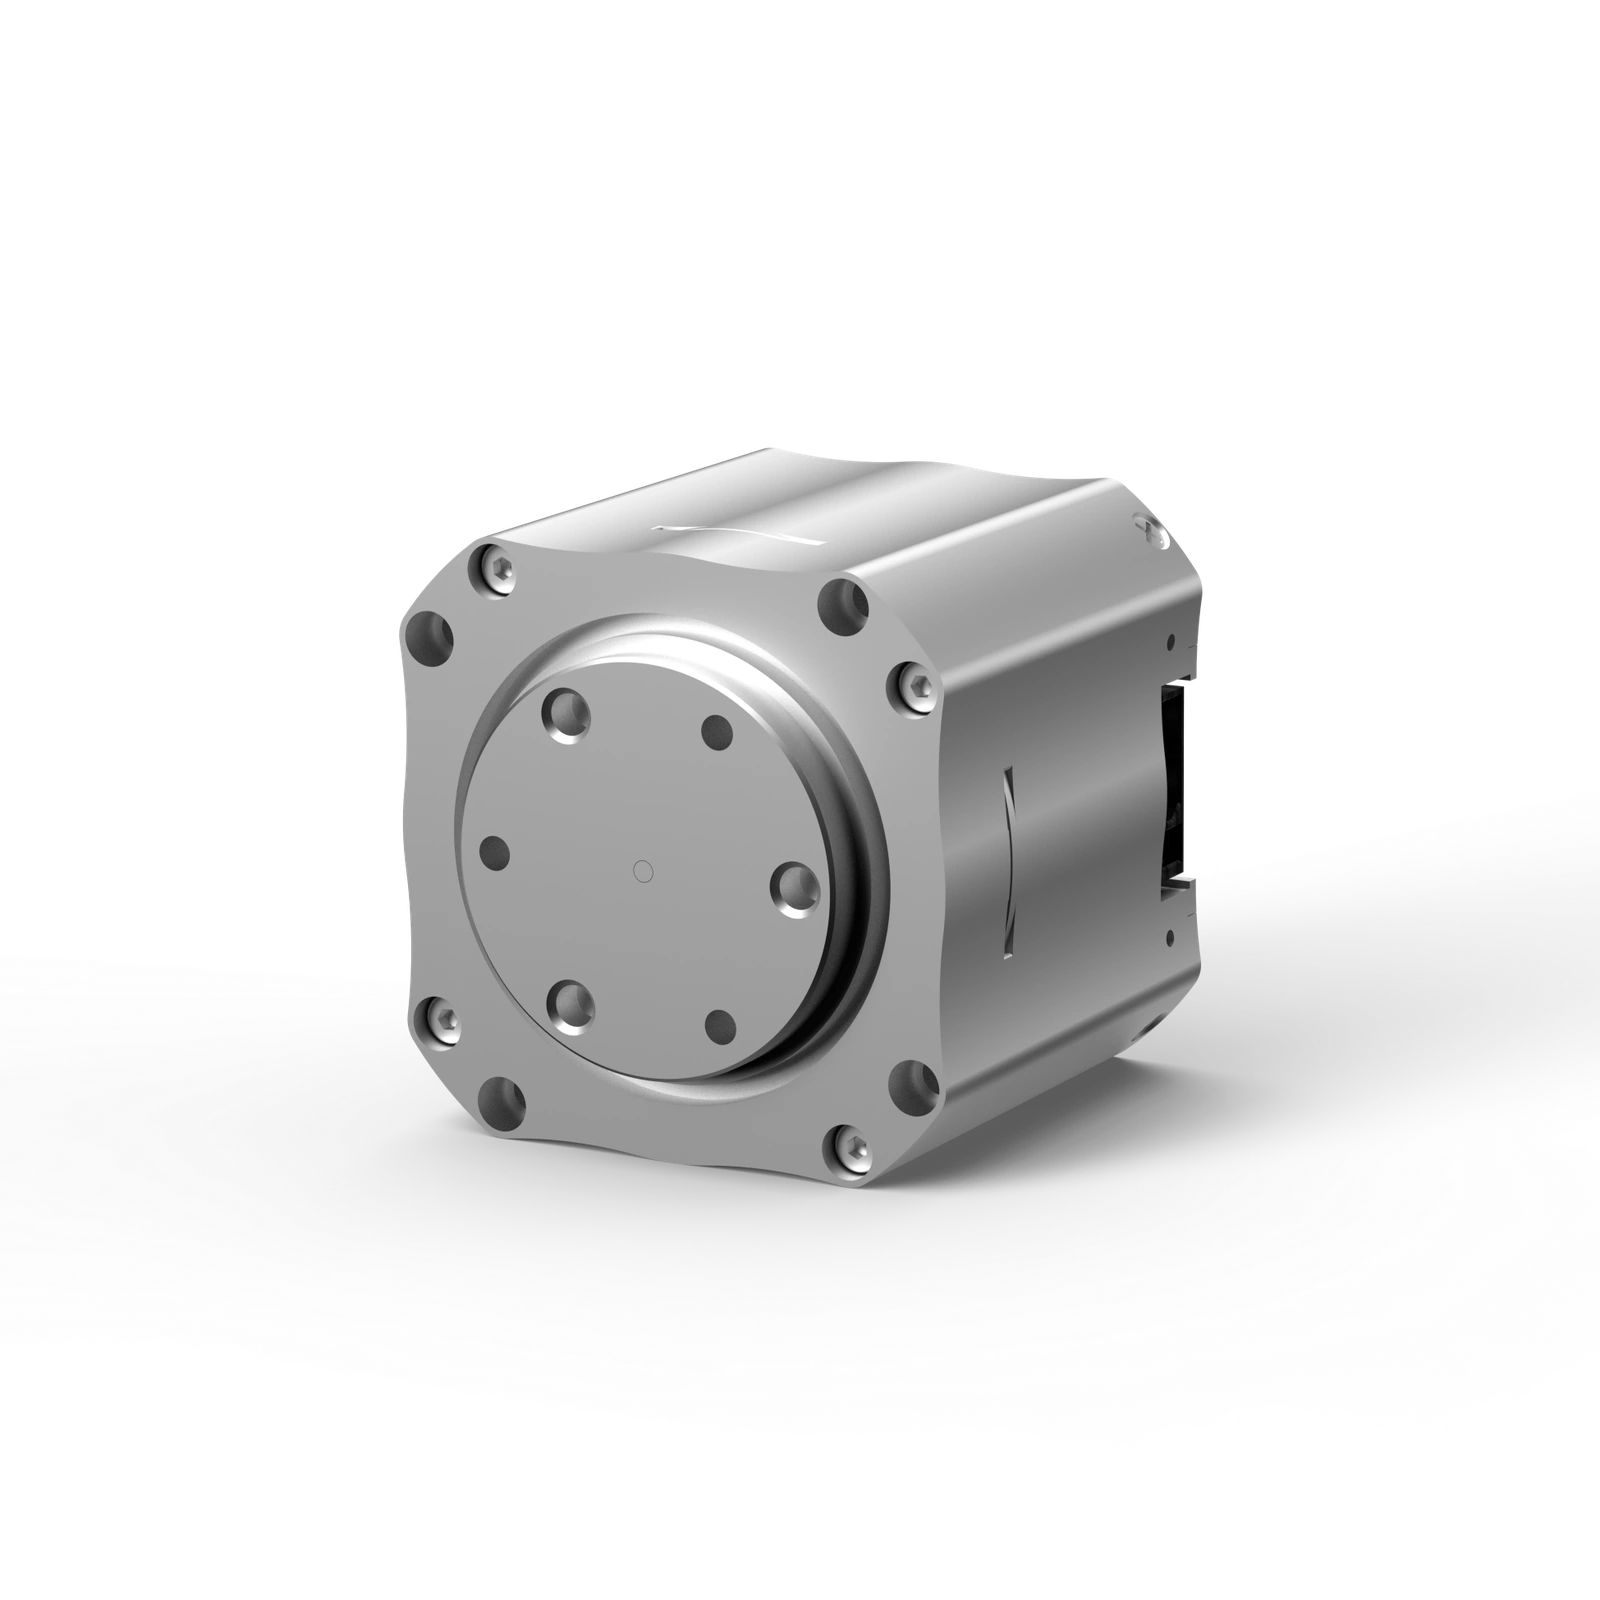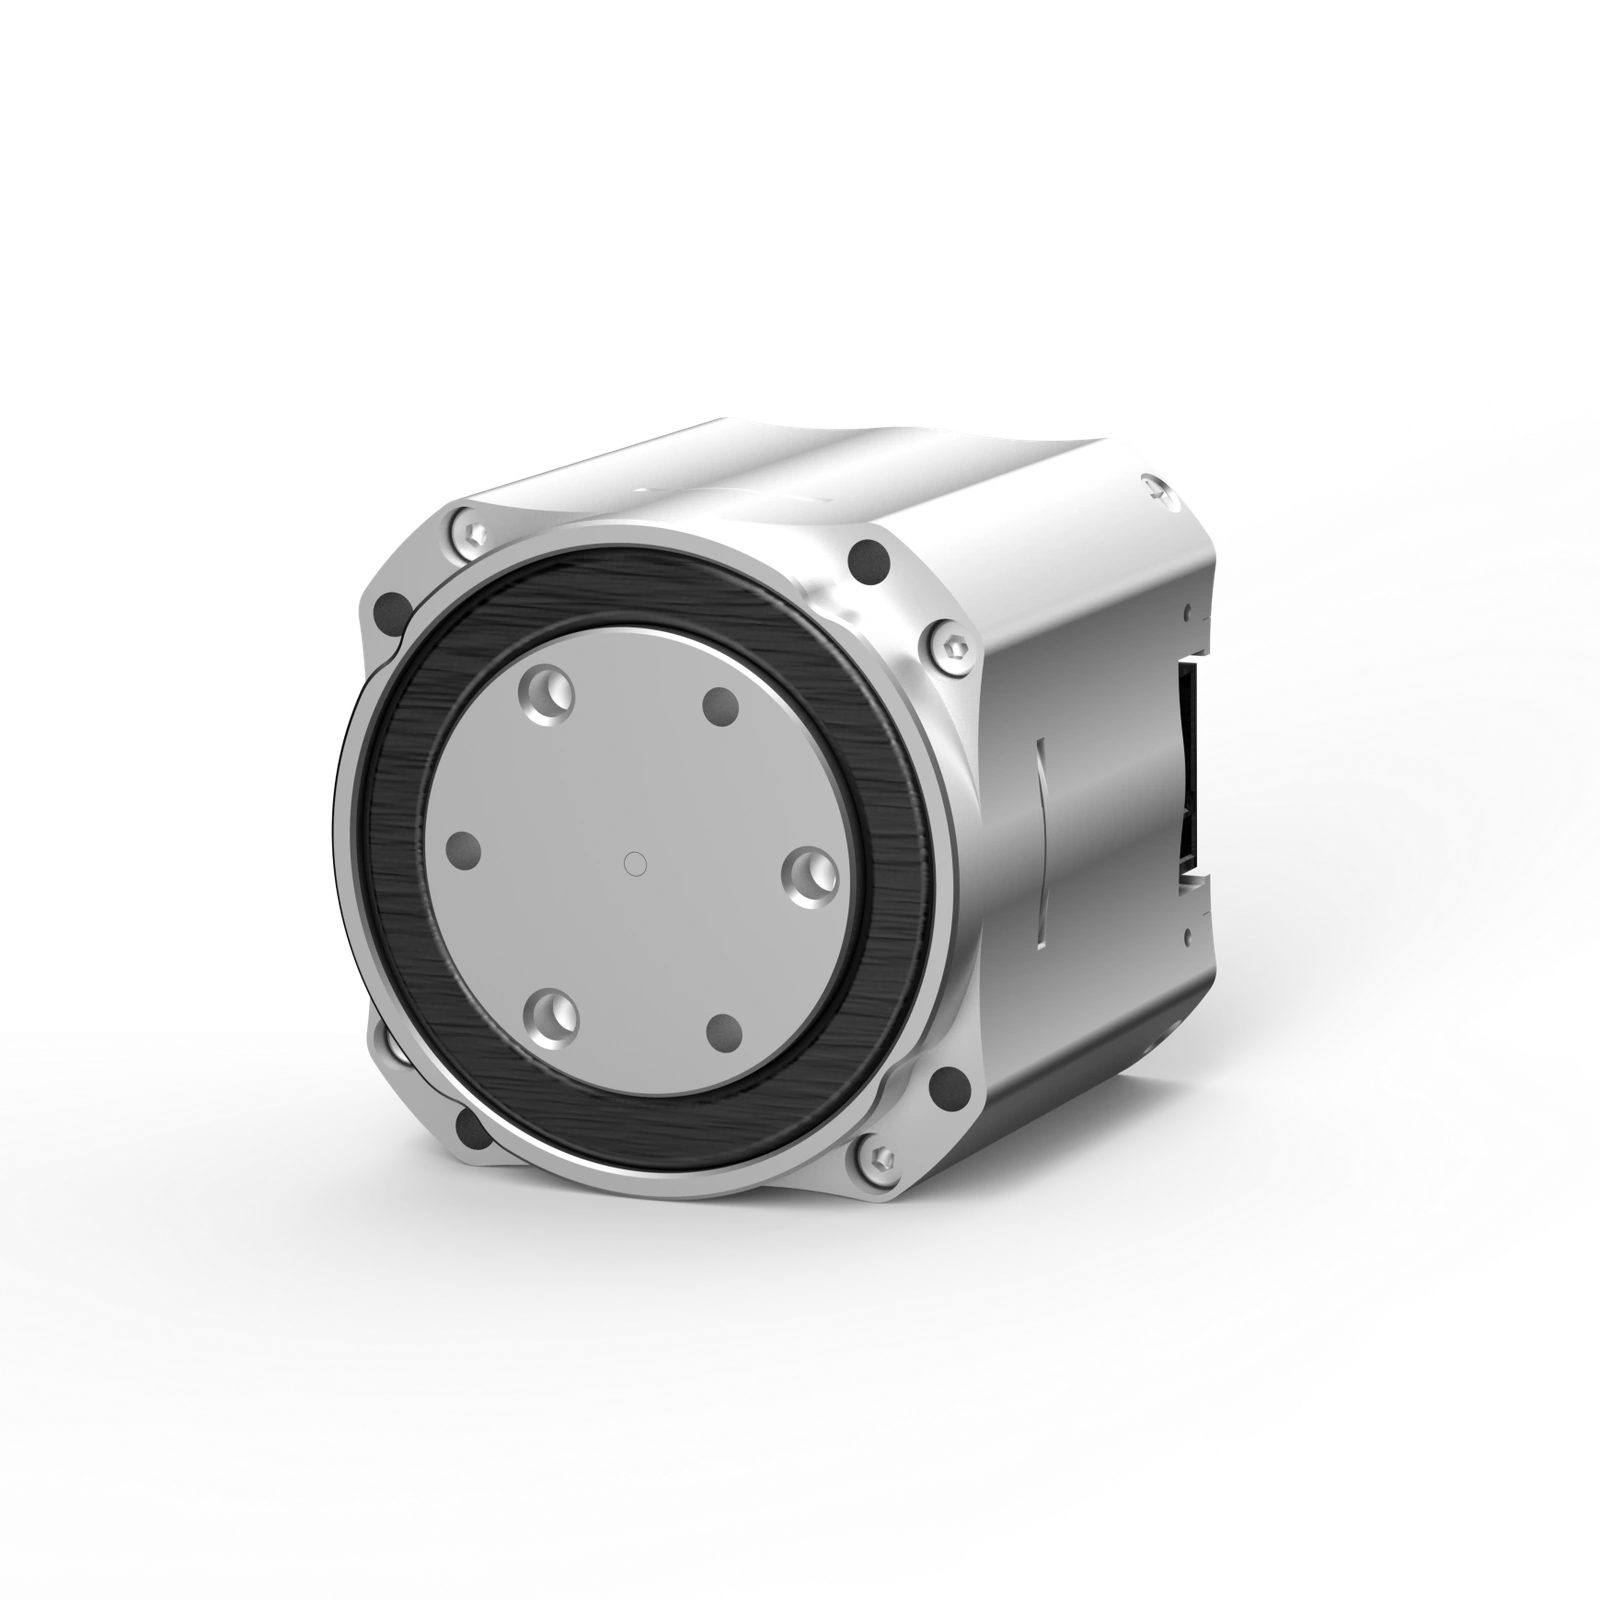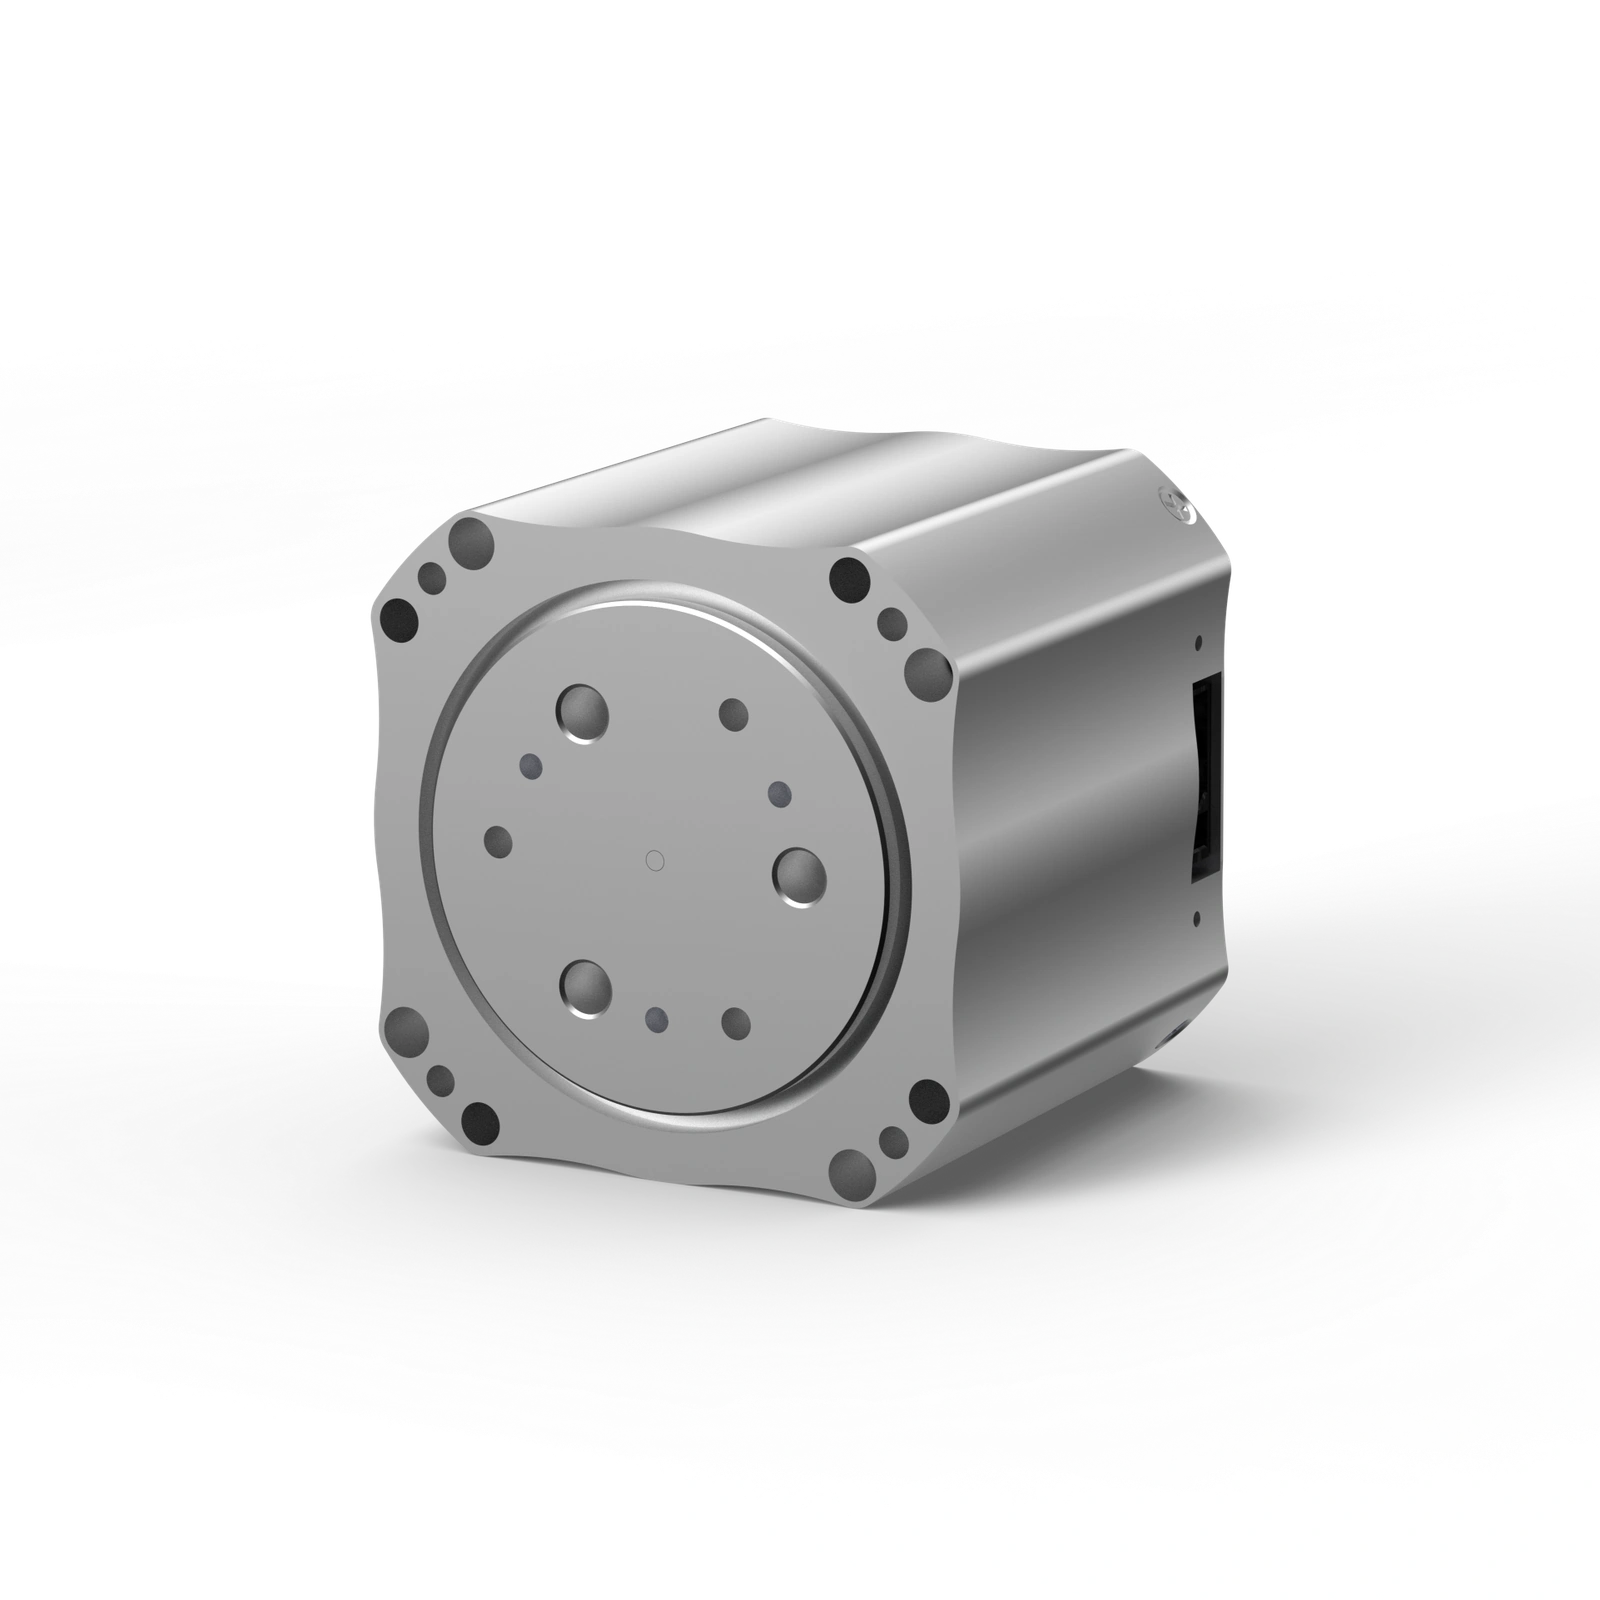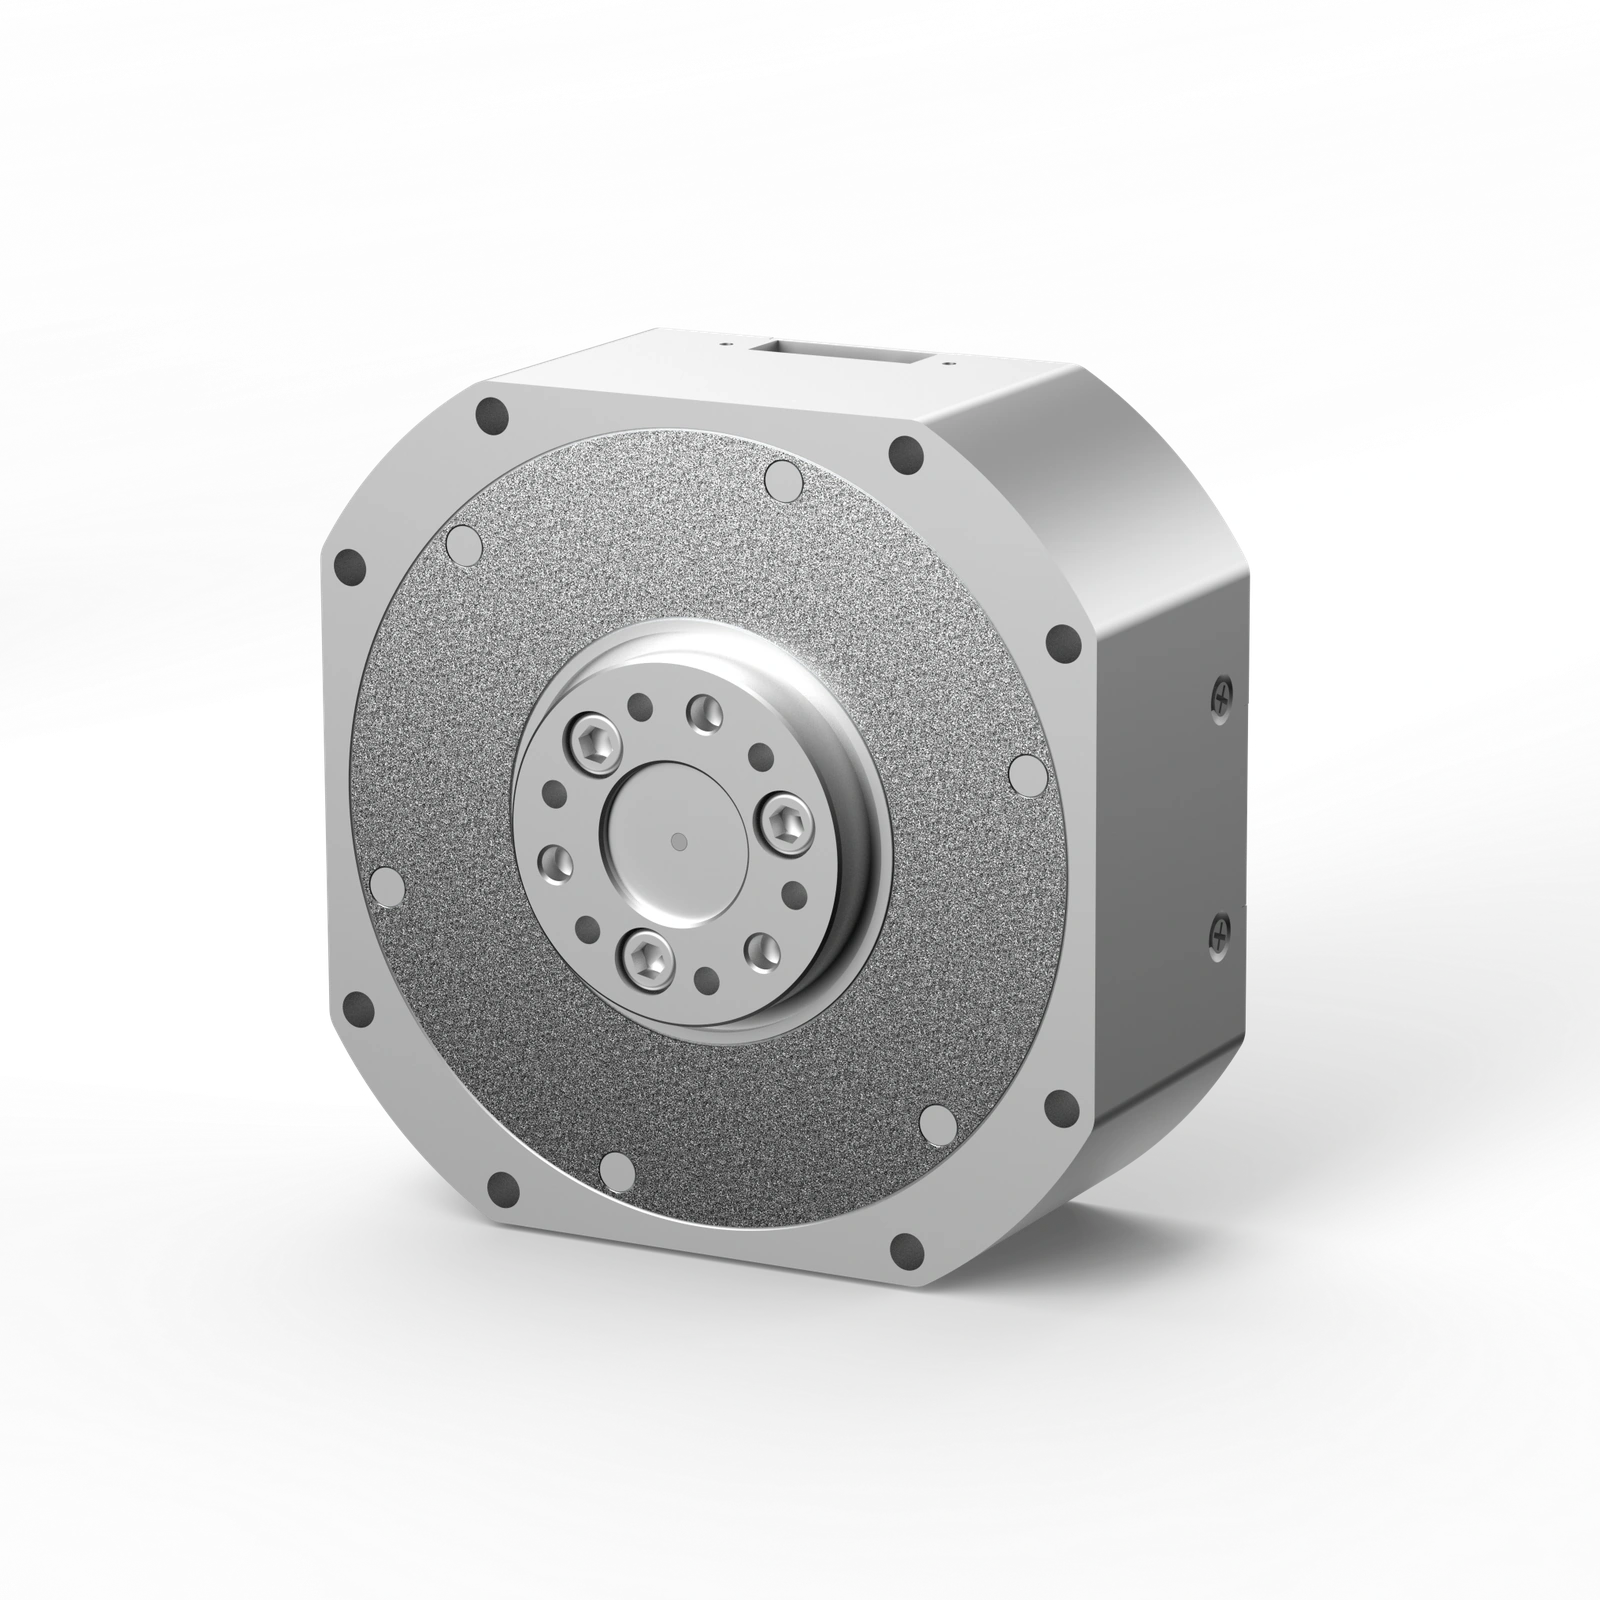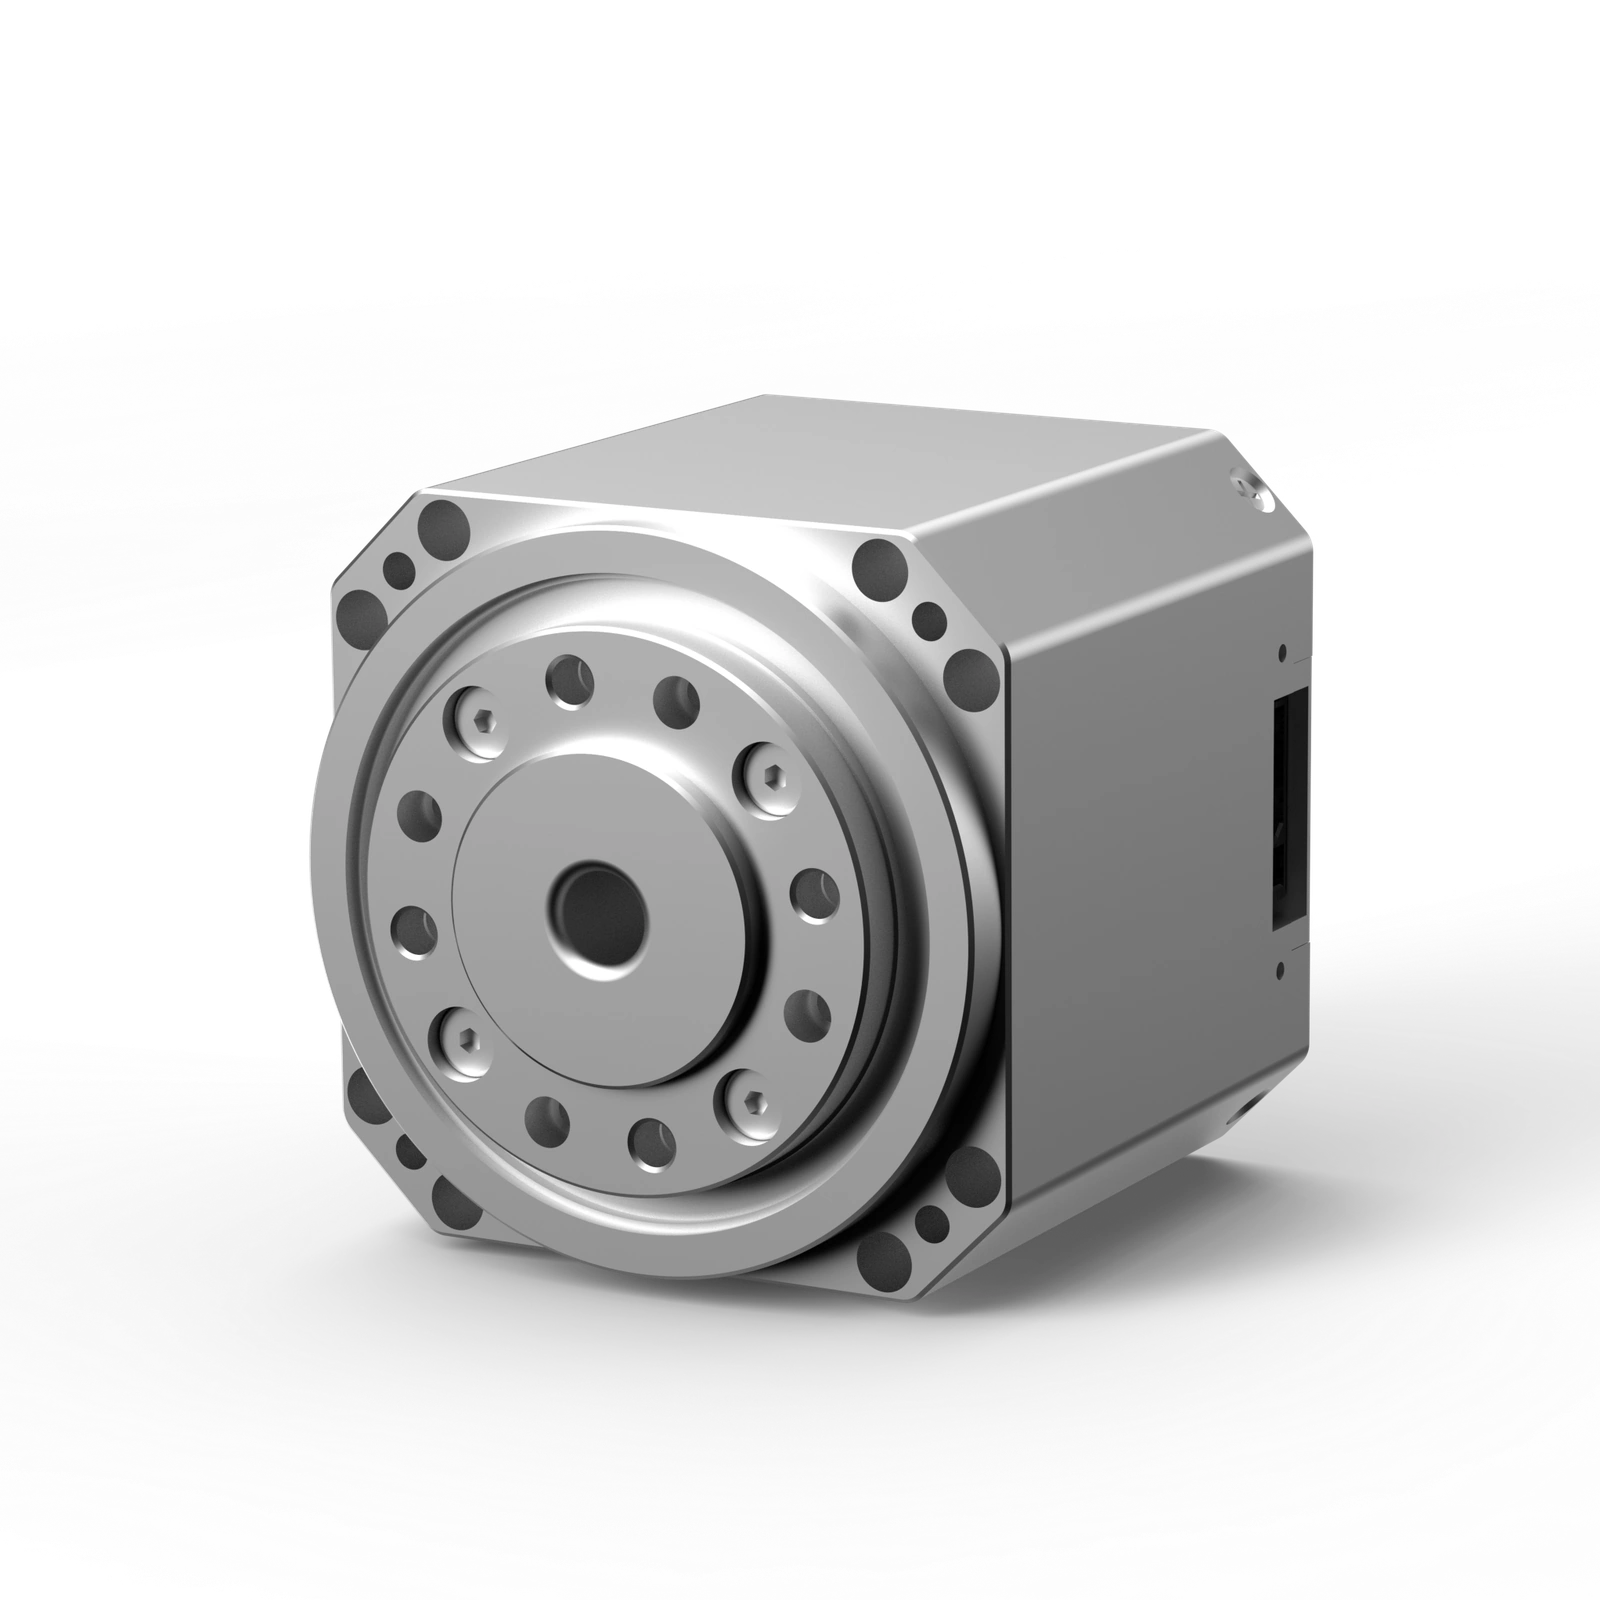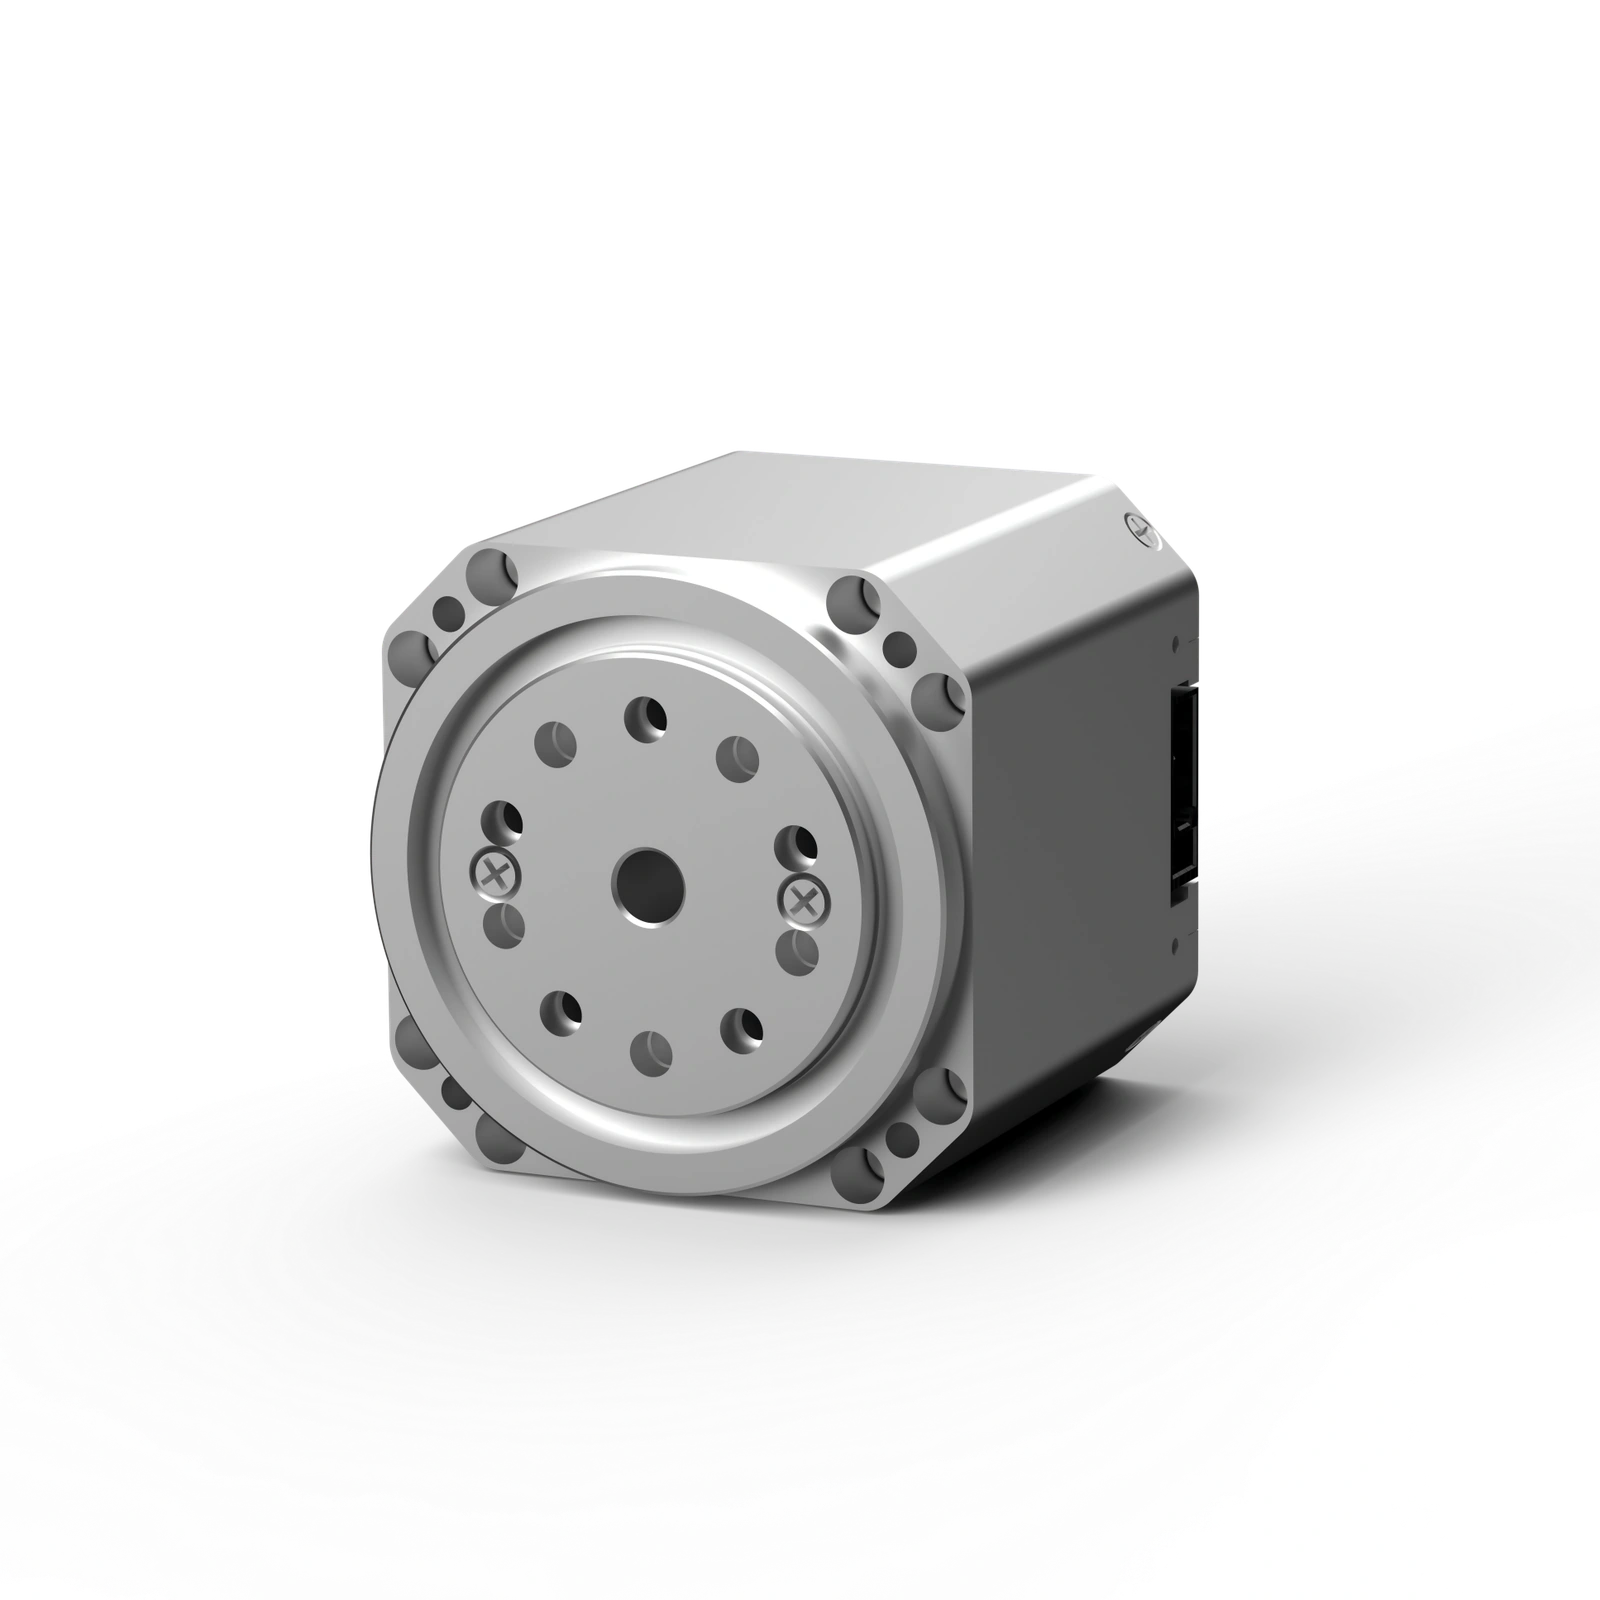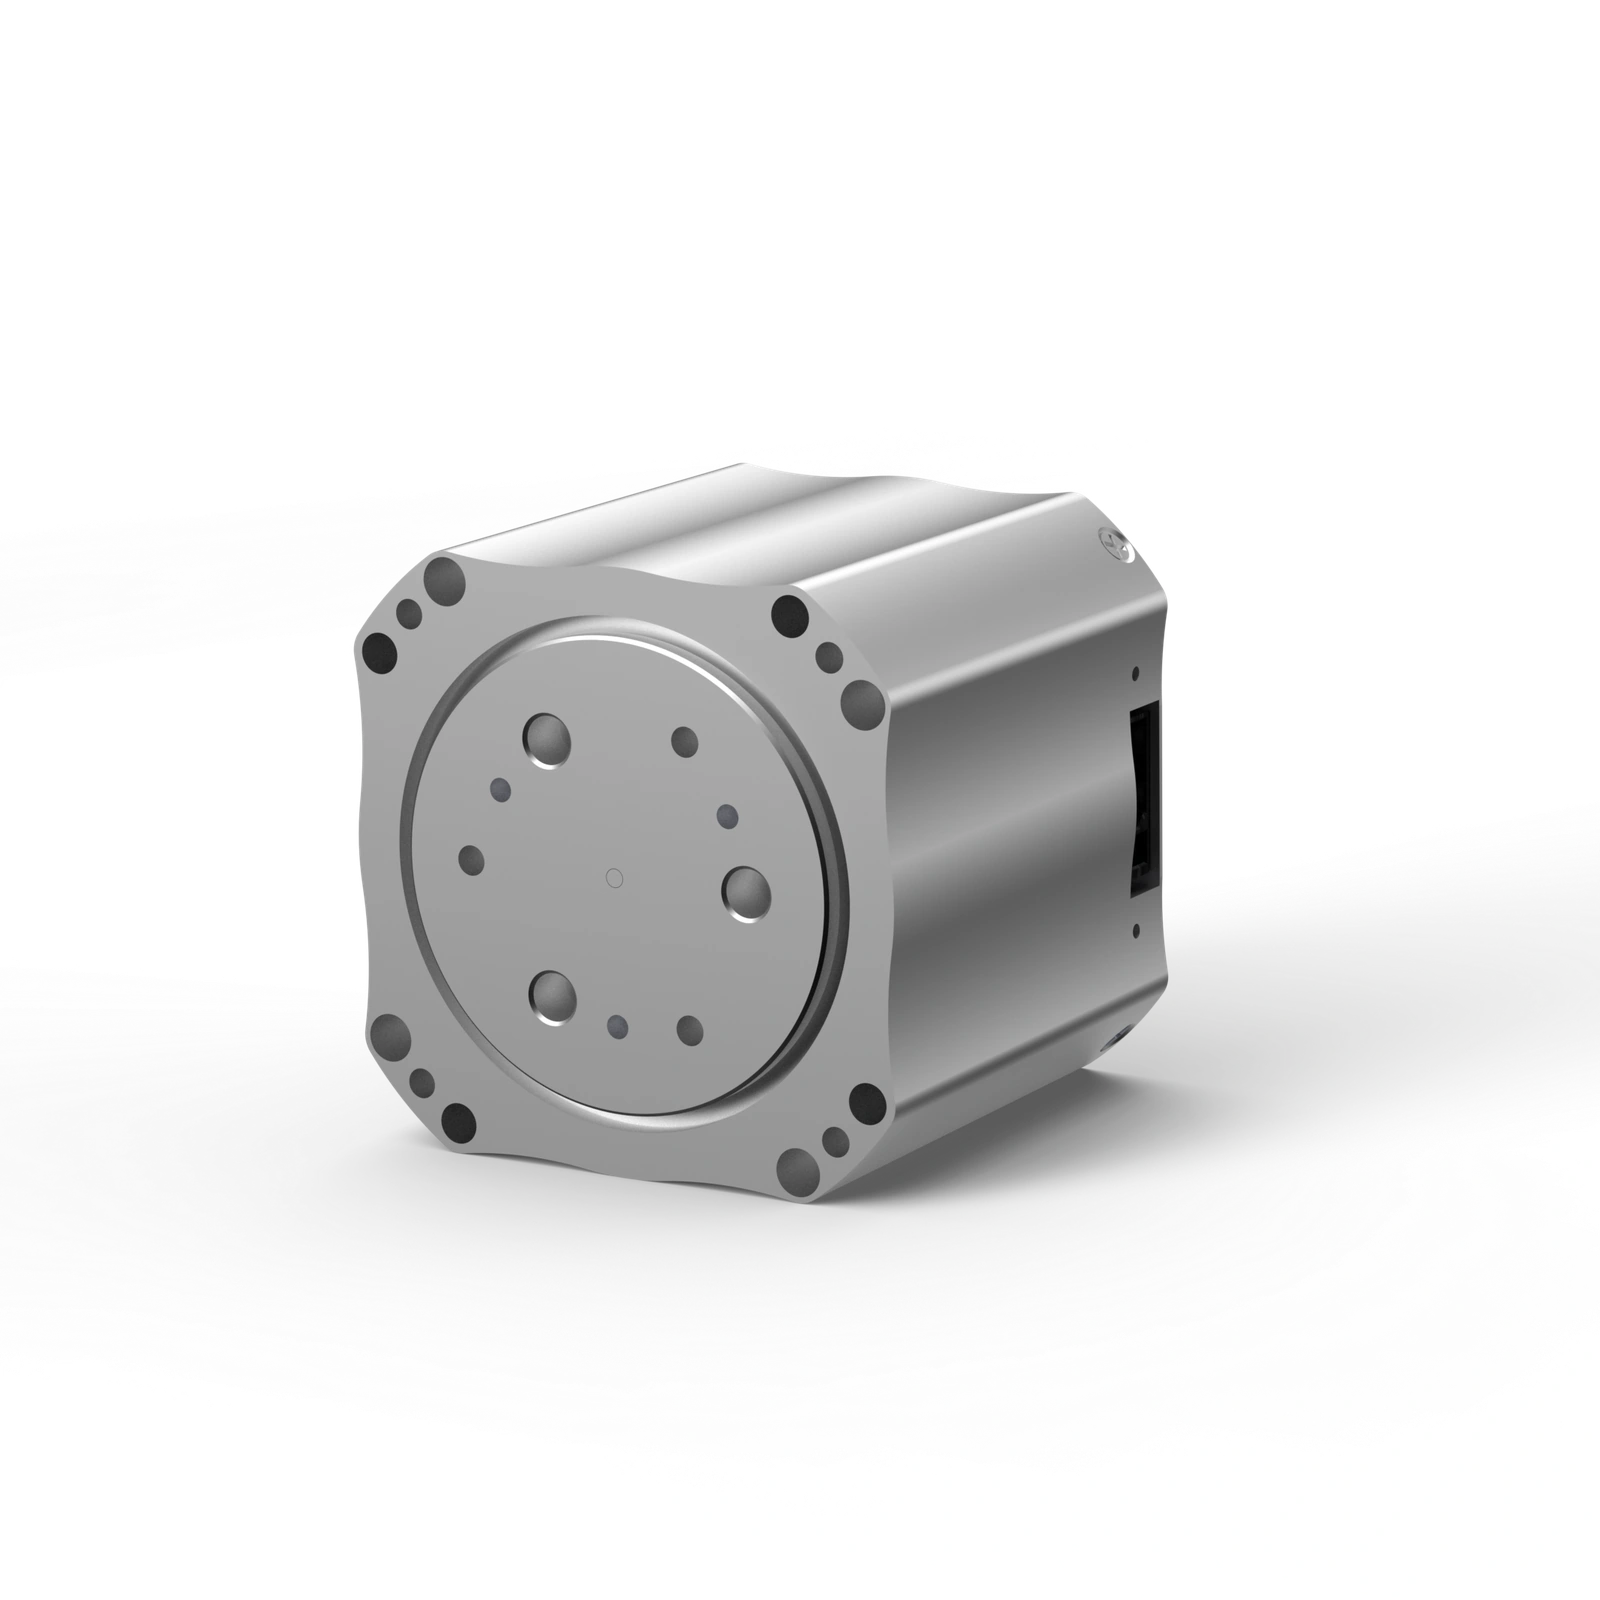
HOTPlanetary Joint Module
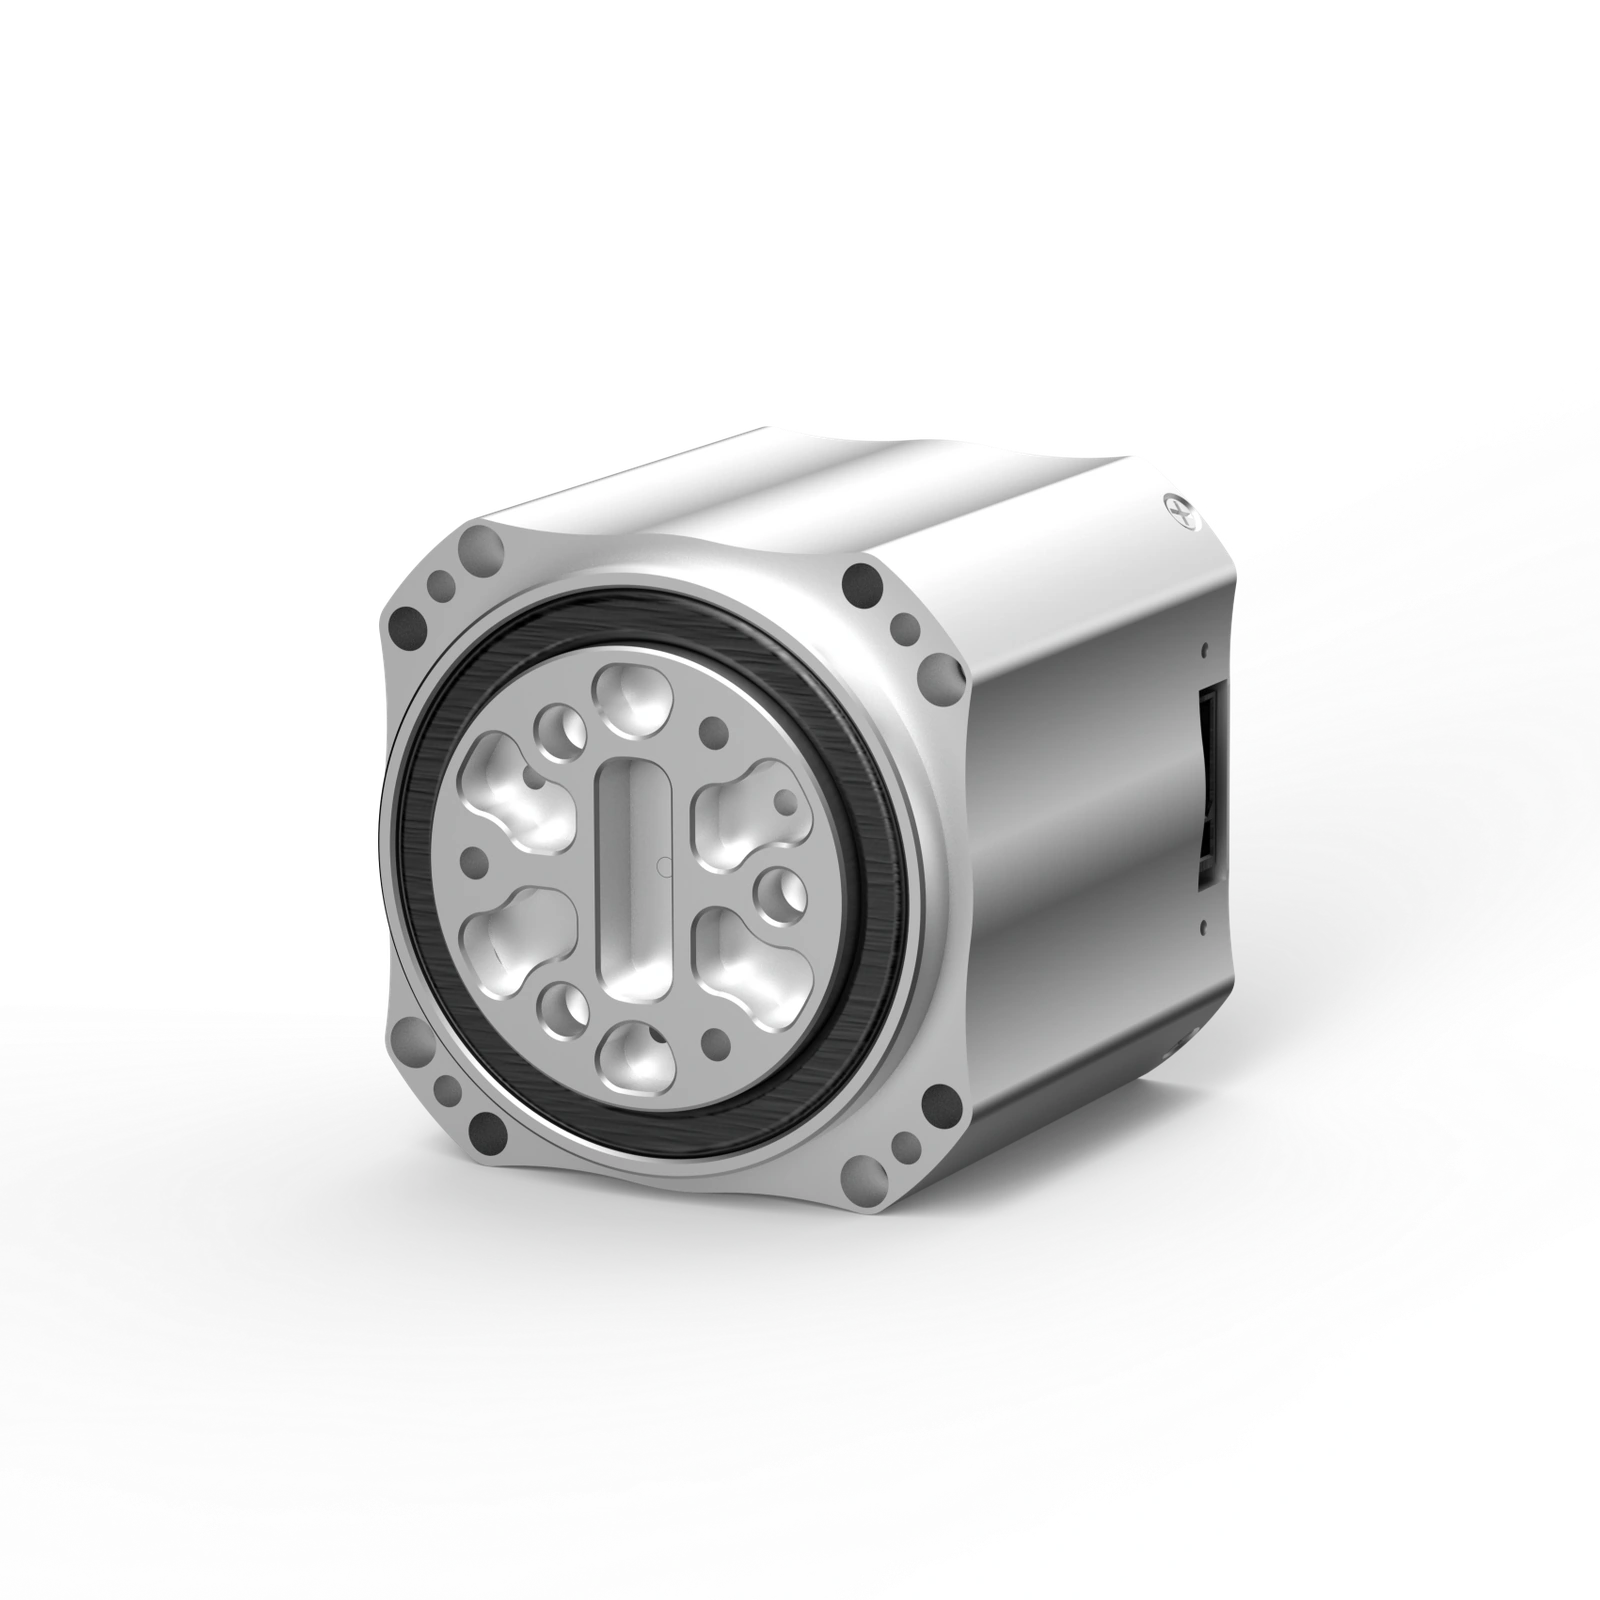
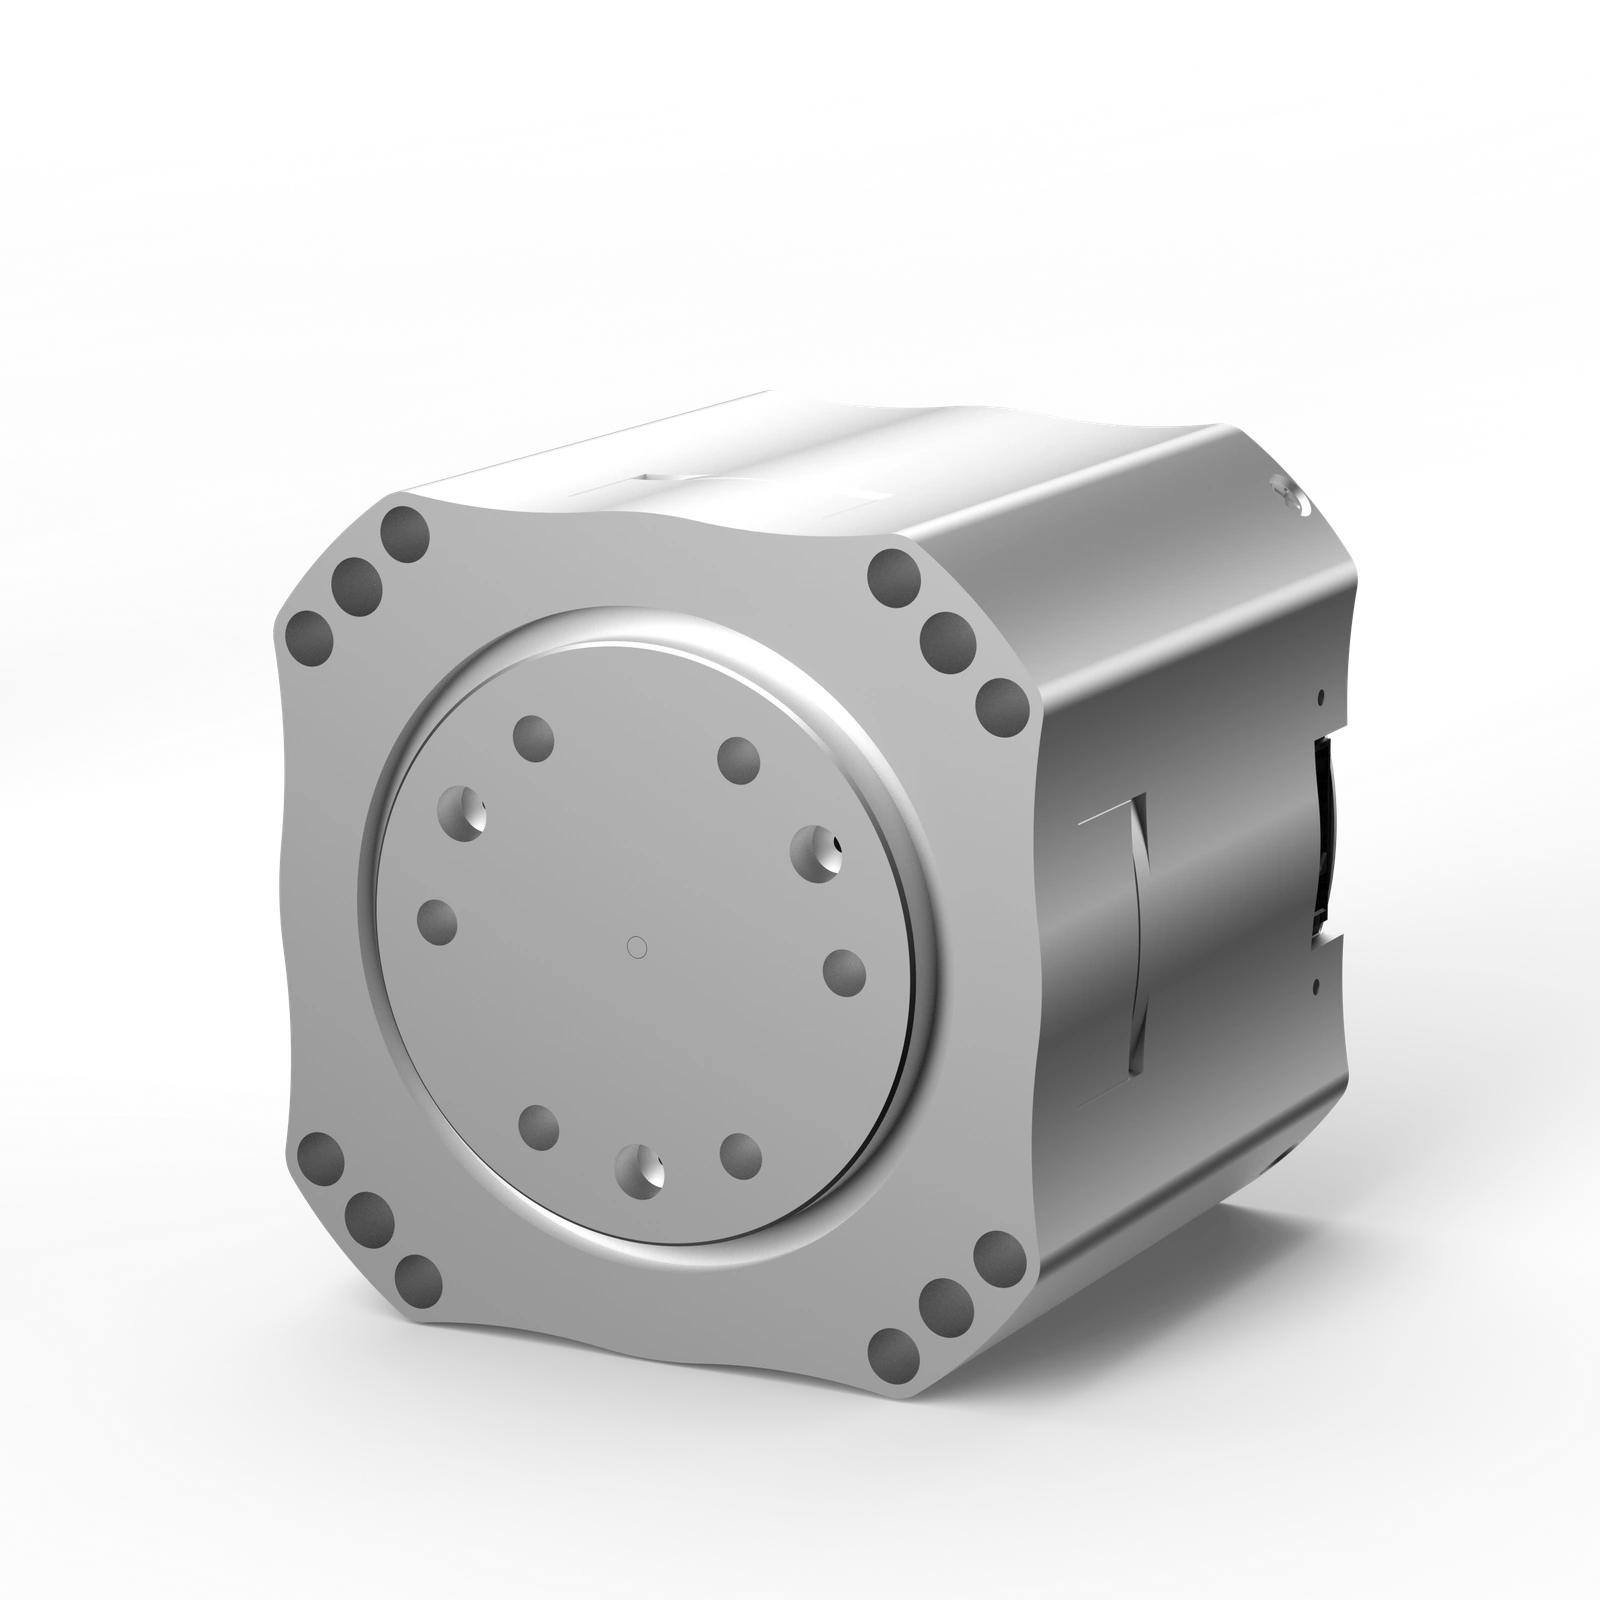
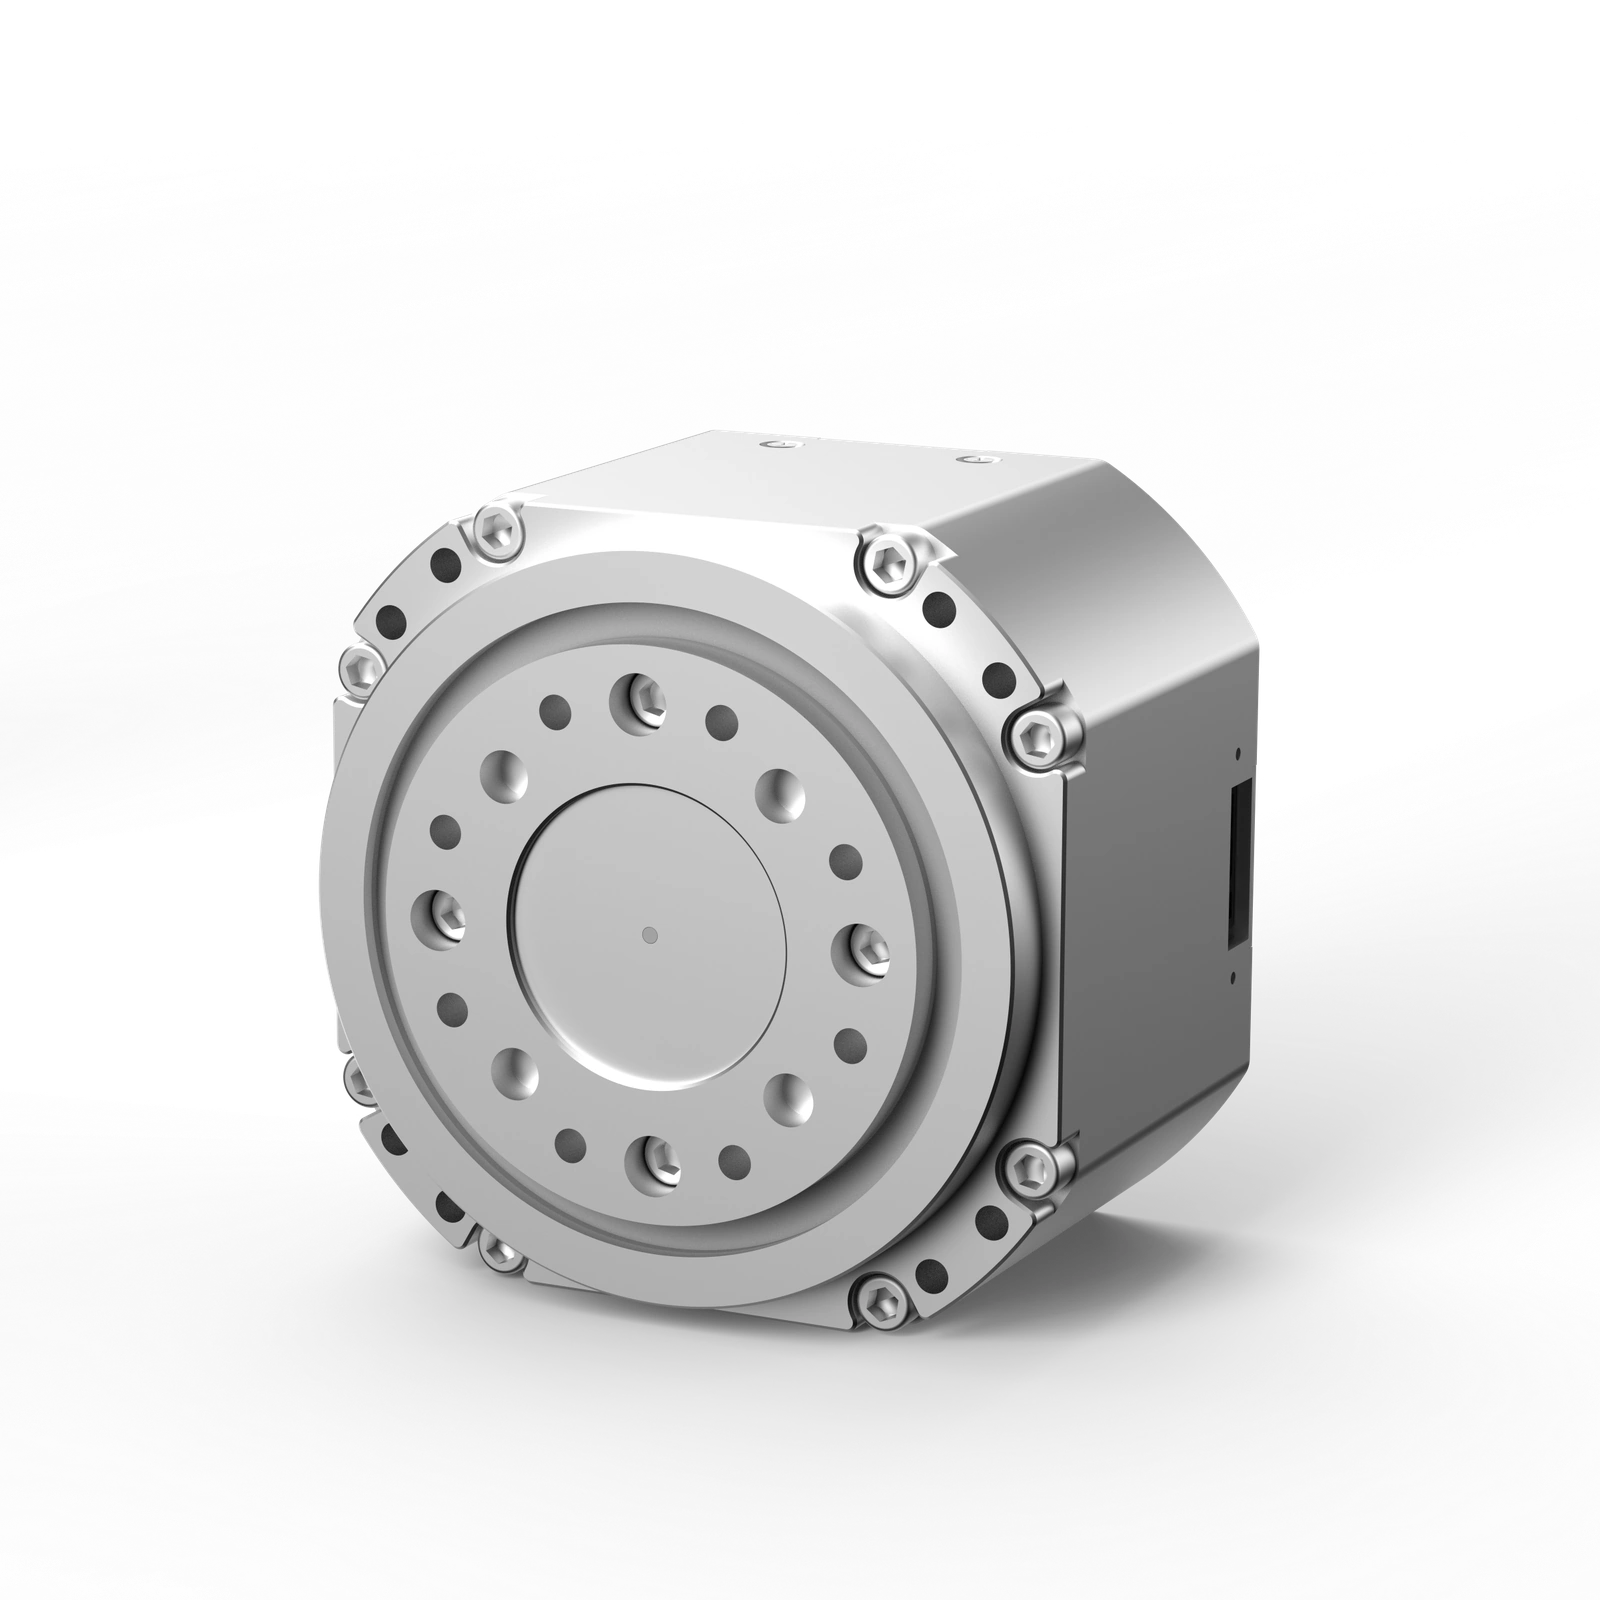
XTR-J105
Planetary joint module rated at 6 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestChoose integrated joint modules for articulated prototypes, then narrow the selection by torque, speed, dimensions and mechanical loads.
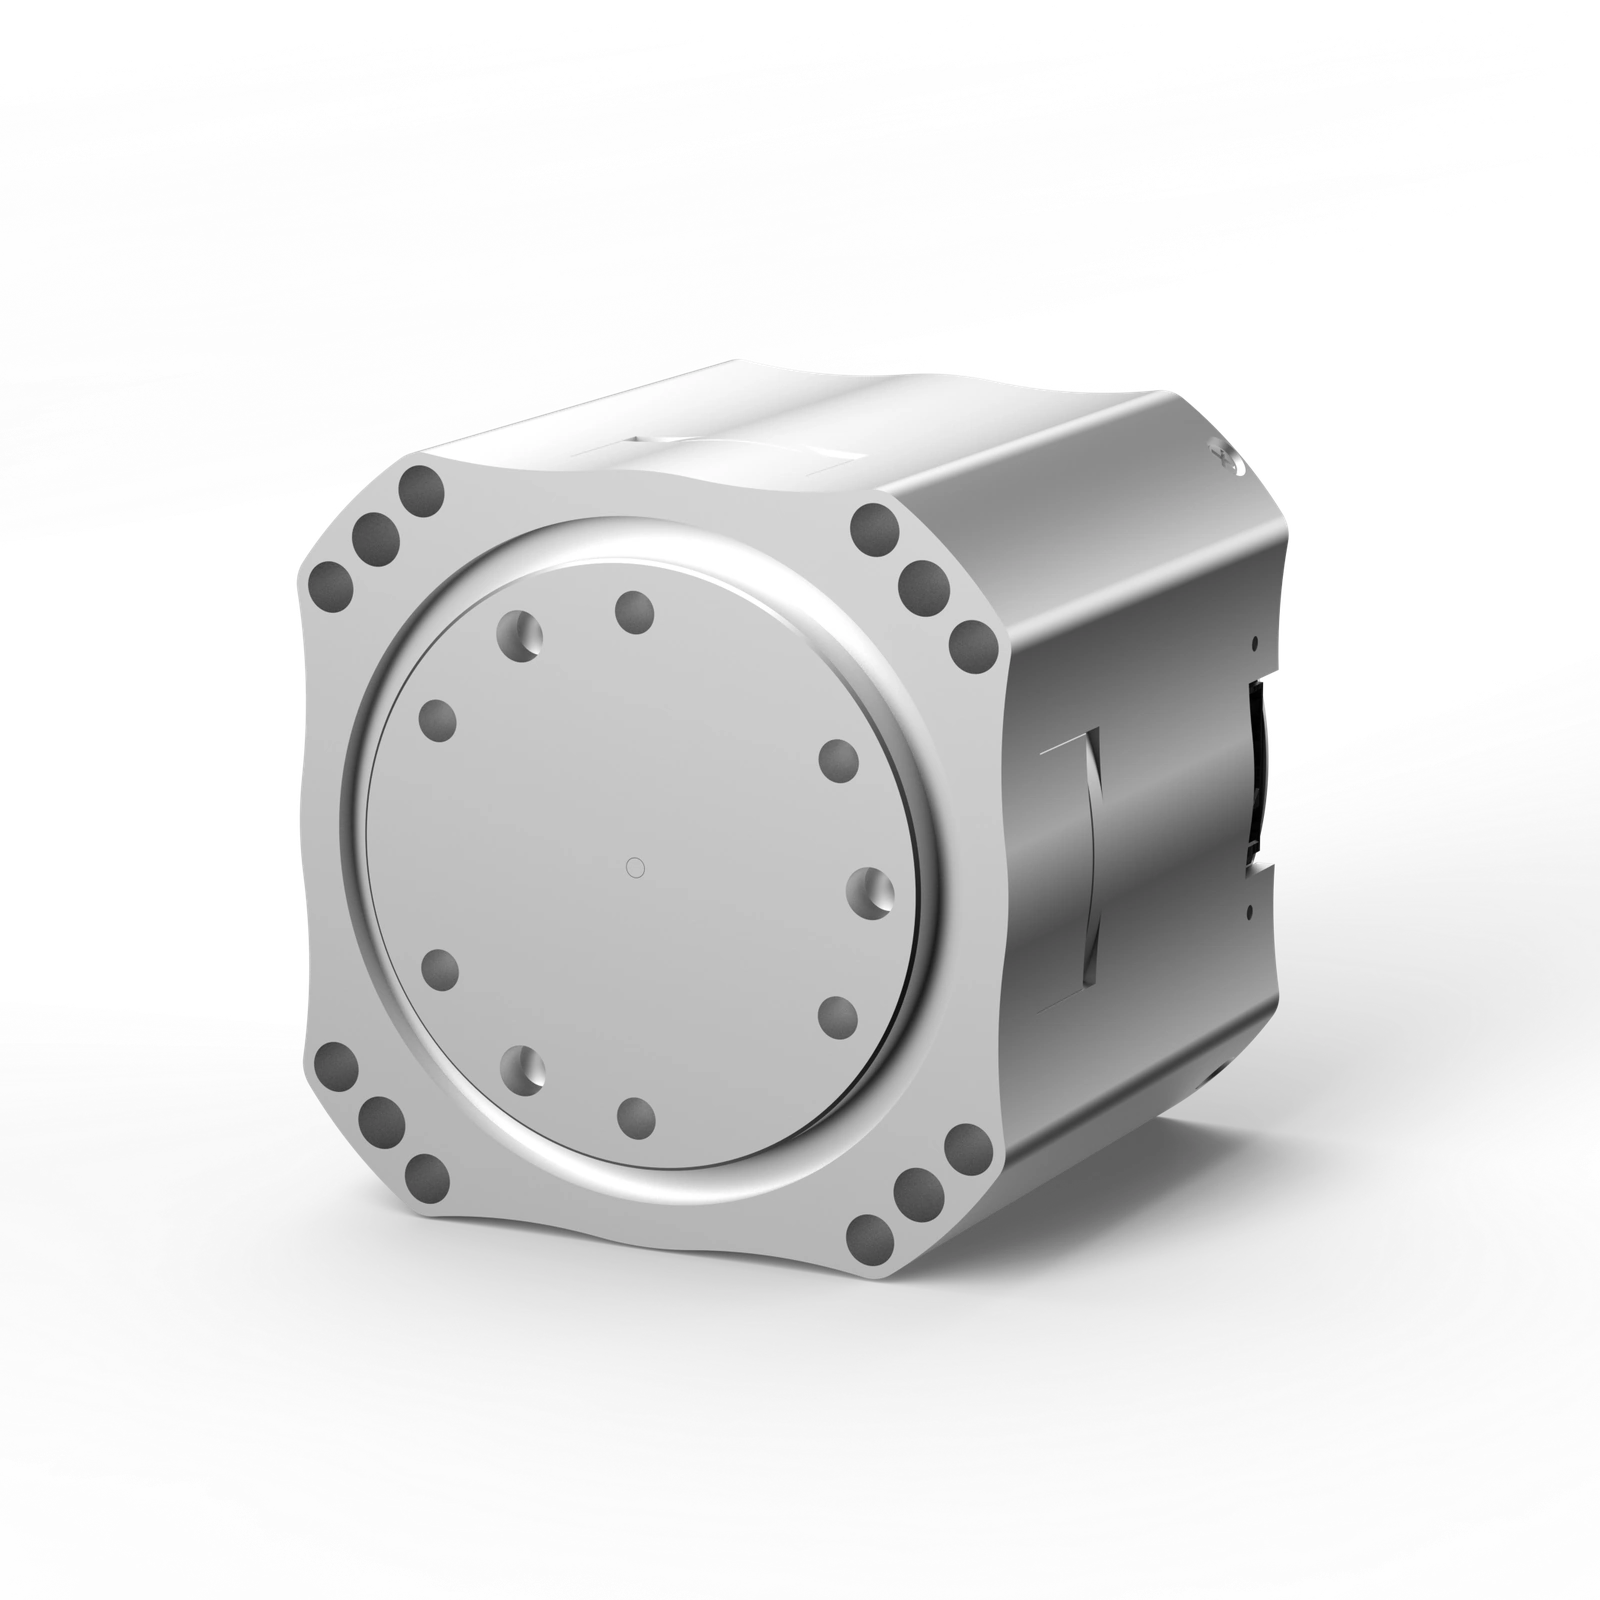
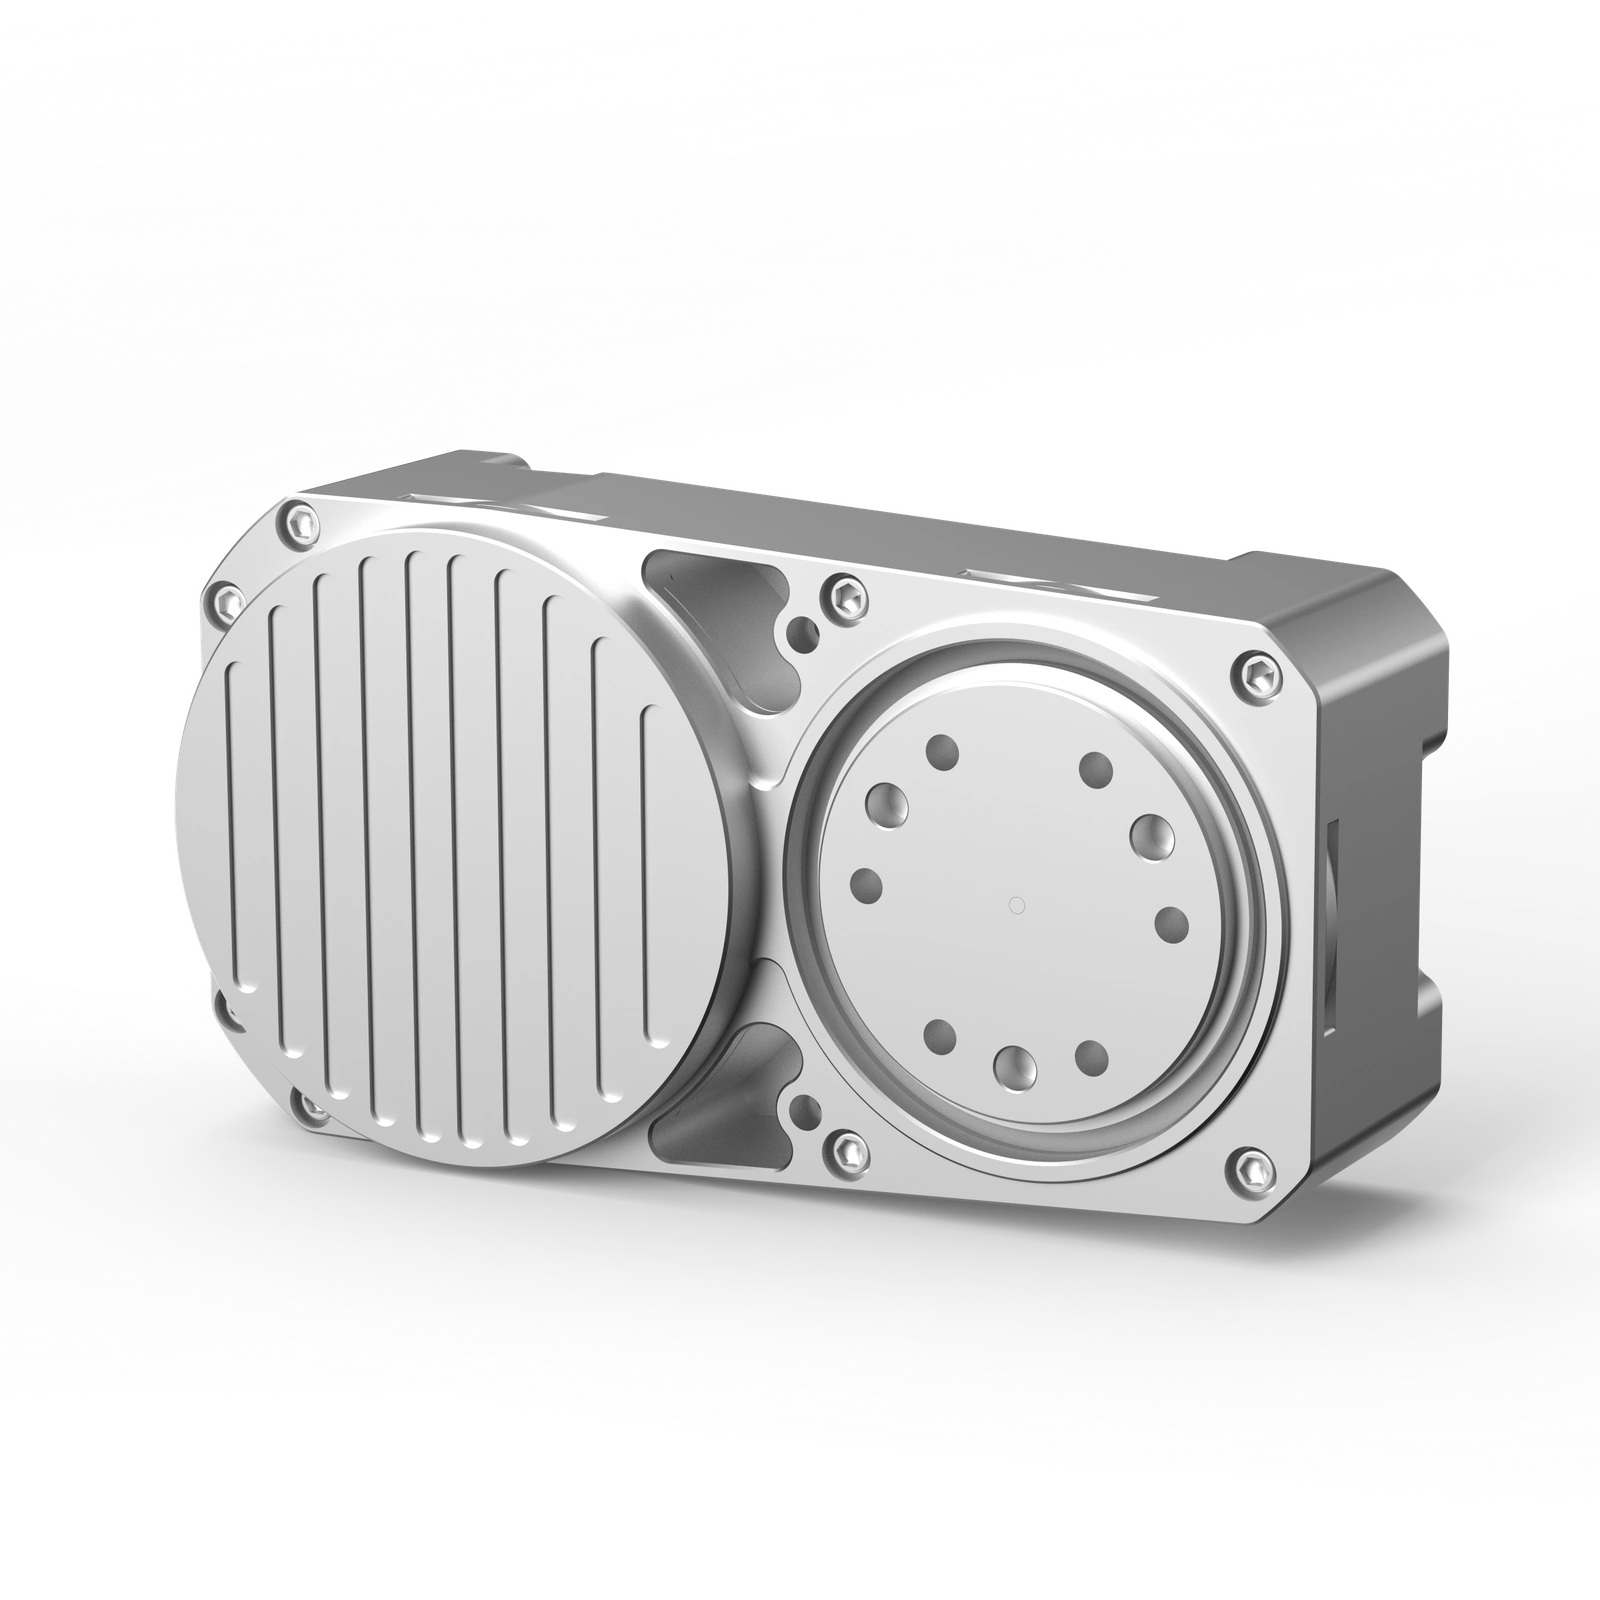
J105/J106 offer rated torque of 6 N·m and J107/J108 offer 10 N·m, all at a listed rated speed of 50 rpm. Explore compact, higher-speed, thin and hollow-bore designs for other constraints.
Indicative guide prices in USD. Confirm exact configuration and quantity pricing in your inquiry.
Planetary joint module rated at 6 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 6 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 10 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 10 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 18 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestUltra-thin joint module rated at 10 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestUltra-thin joint module rated at 20 N·m and 40 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 2 N·m and 40 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 2 N·m and 40 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 3.5 N·m and 82 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 4 N·m and 250 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestHollow-bore joint module rated at 4 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestHollow-bore joint module rated at 2 N·m and 40 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestCalculate load, inertia, thermal conditions and duty cycle. Confirm bearings, mounting flanges and mechanical differences between paired models before treating them as interchangeable.
Prepare your requirementsSelect models and quantities, describe your application and prepare a request for configuration-specific or wholesale pricing.