Custom robot joints
- Building custom articulated arms
- Prototyping limb joints and multi-joint mechanisms
- Comparing actuator sizes for a new robot design
View full-size image ↗ · 2401 × 2401 px
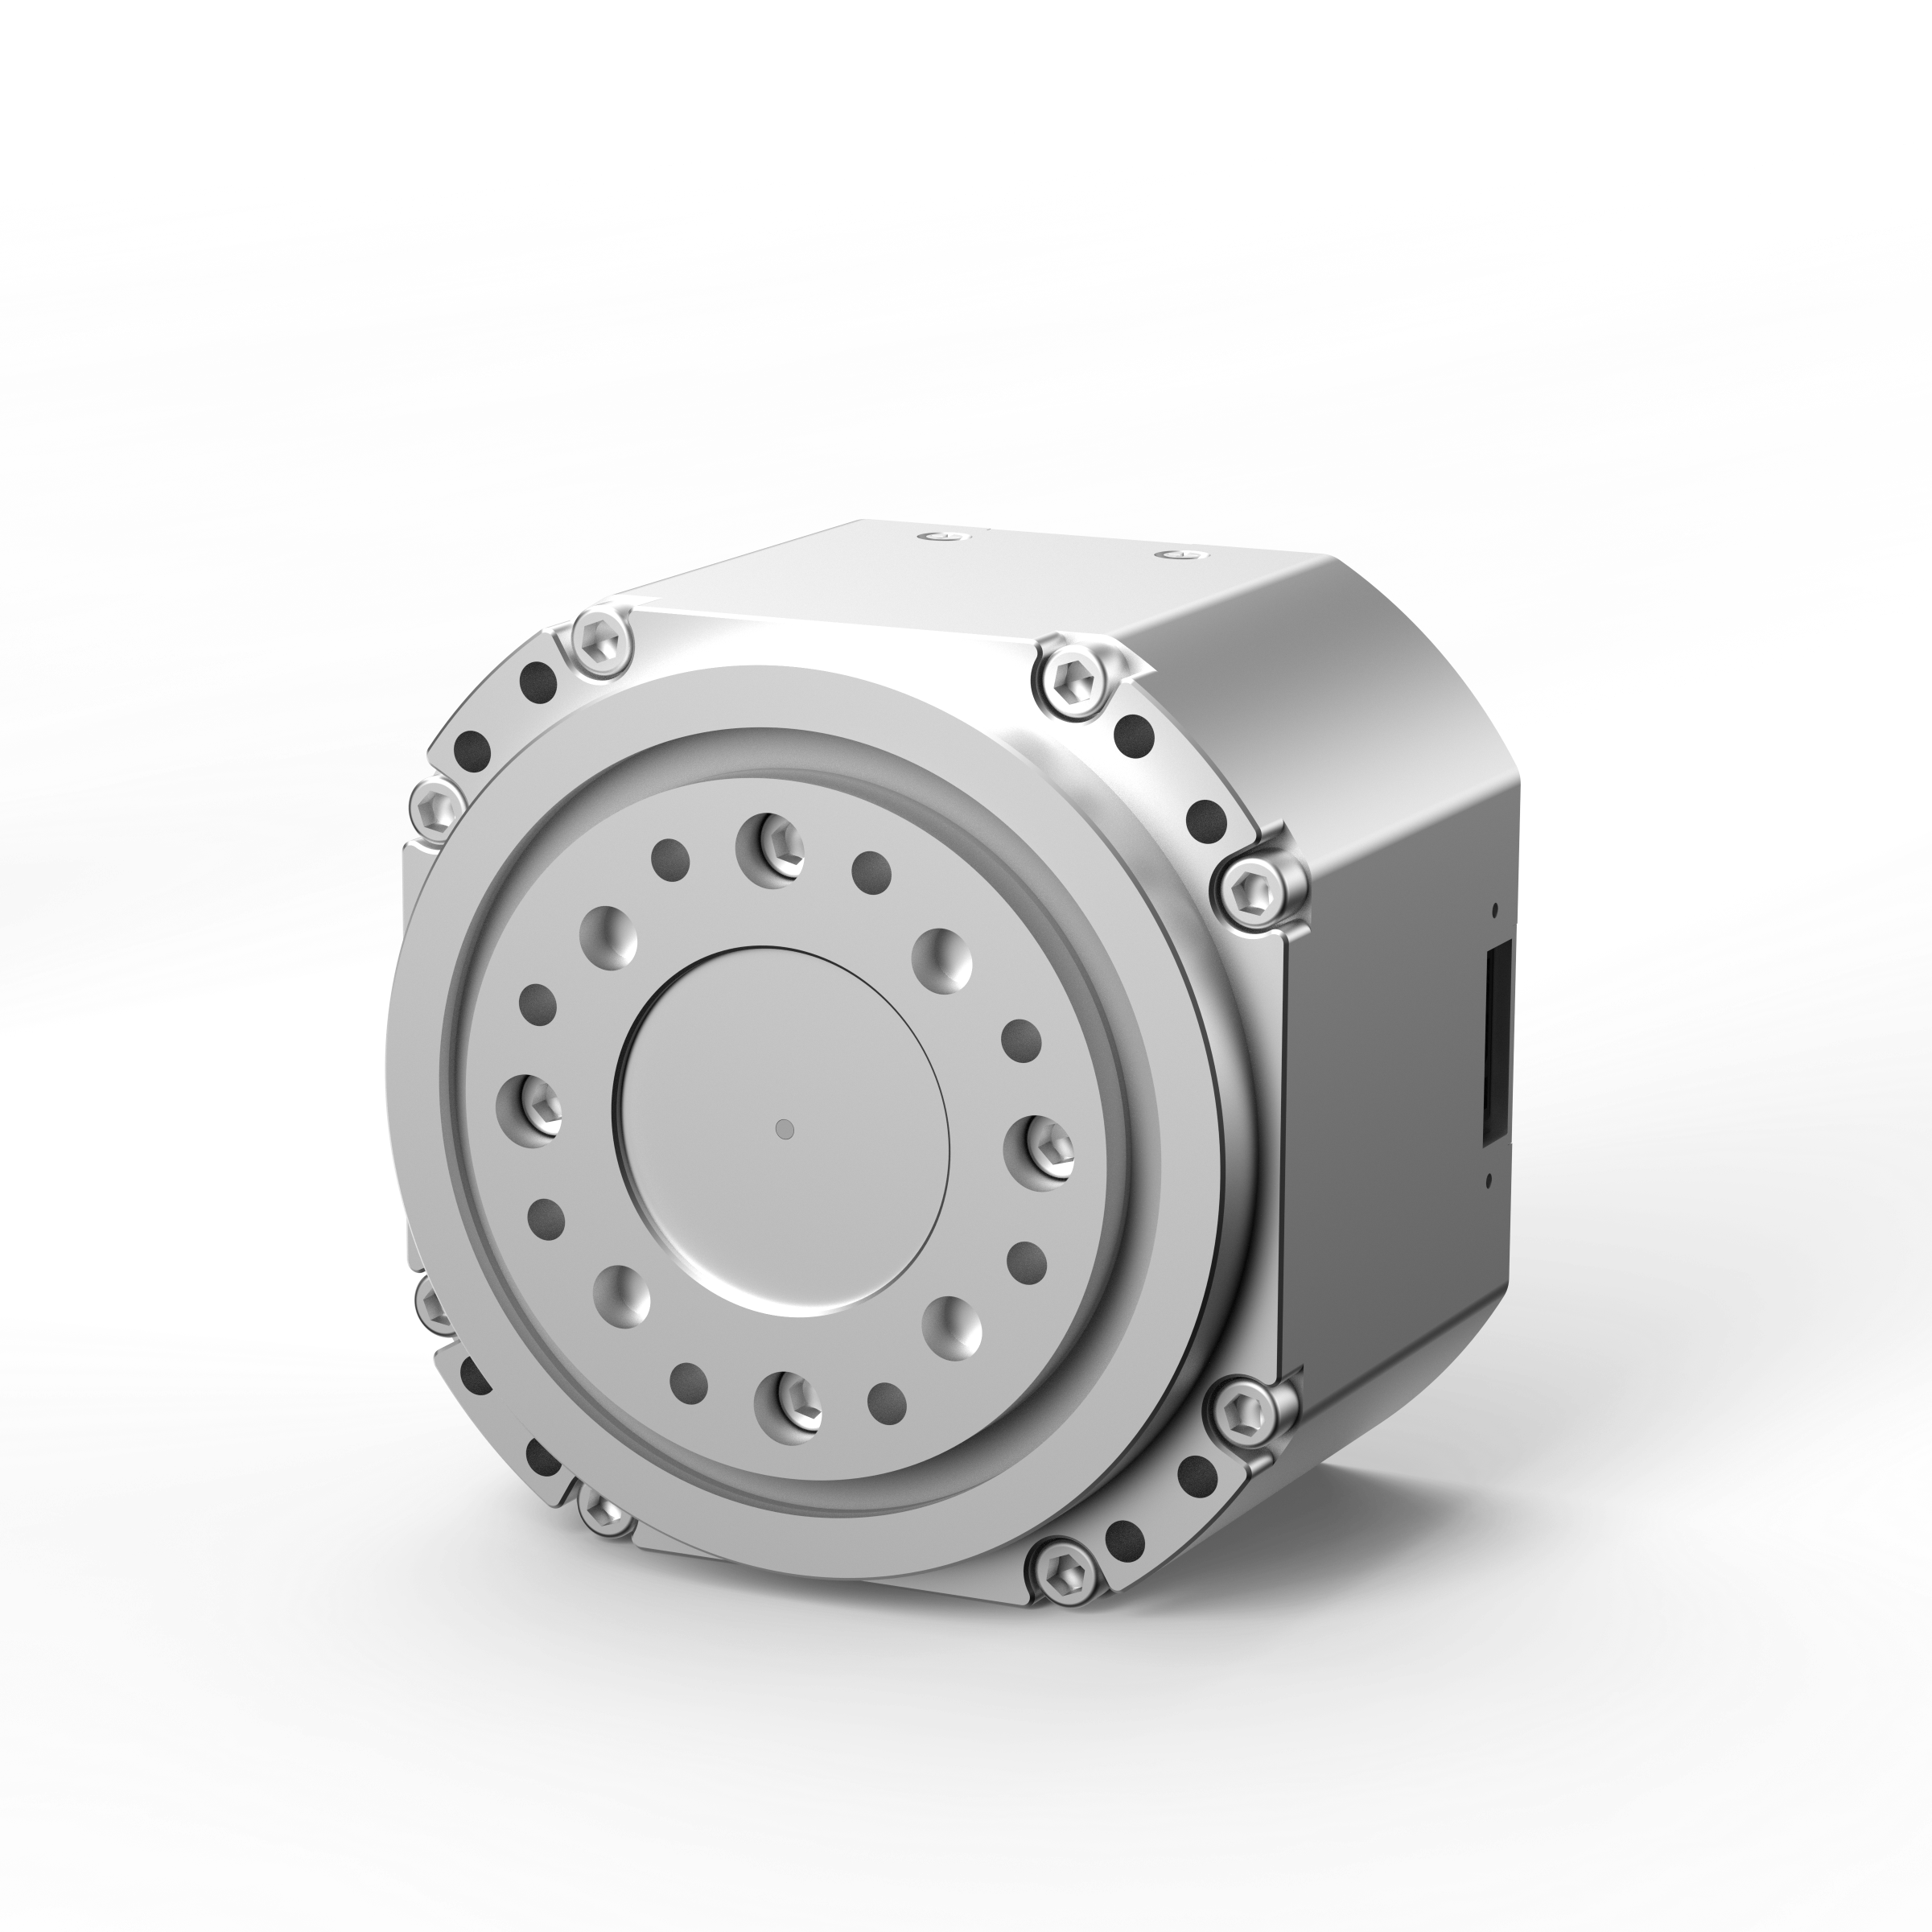
Product image. Confirm the selected configuration before ordering.
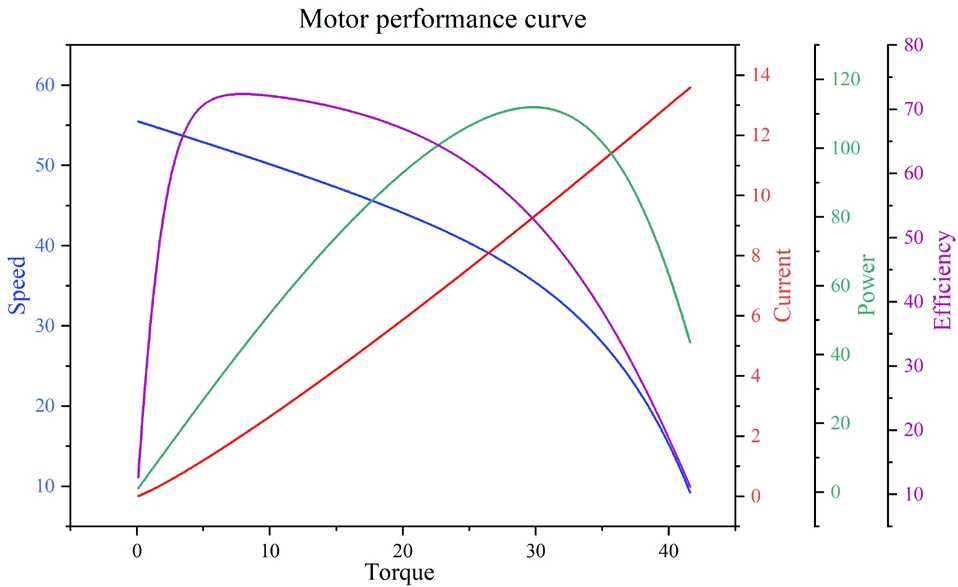
Planetary joint module rated at 18 N·m and 50 rpm, with CAN FD / CAN communication.
Catalog specifications · page 16Application guidance is based on the listed hardware and development resources. Confirm the software, sensors and integration your project needs.
Calculate load, inertia, thermal conditions and duty cycle. Confirm bearings, mounting flanges and mechanical differences between paired models before treating them as interchangeable.
Determine the joint location from system-level loads, inertia and the working cycle. Confirm cooling and support structure; do not size continuous operation from stall torque.
| Parameter | Value |
|---|---|
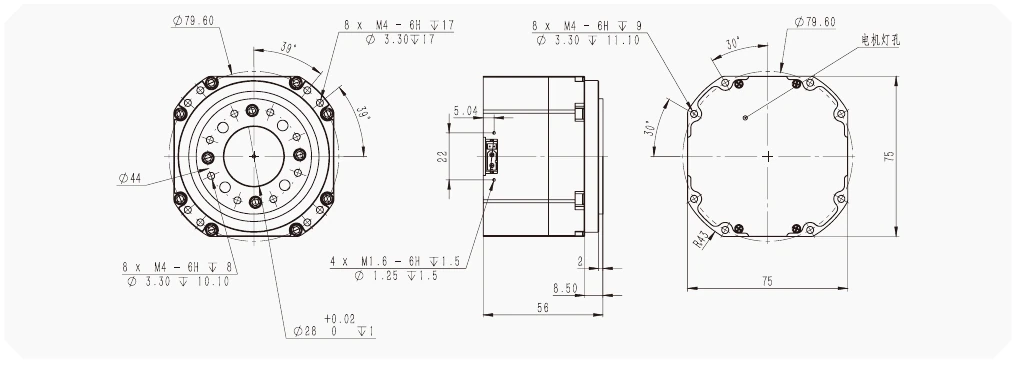
| Length and width | 75 mm |
| Height | 56 mm |
| Weight | 850 g |
| Parameter | Value |
|---|---|
| Reduction ratio | 35:1 |
| Rated voltage | 24 V |
| Rated current | 4.2 A |
| Rated torque | 18 N·m |
| Stall torque | 60 N·m |
| Rated speed | 50 rpm |
| No-load speed | 60 rpm |
| Rated output power | 94 W |
| Parameter | Value |
|---|---|
| Torque constant | 0.602 N·m/A |
| Pole pairs | 14 |
| Parameter | Value |
|---|---|
| Voltage range | 12 to 50.4 V |
| Peak current | 20 A |
| Speed control accuracy | ±10% |
| Torque control accuracy | ±10% |
| Communication | CAN FD / CAN |
| Response time | 140 µs |
| Input encoder resolution | 14 bit |
| Output encoder resolution | 14 bit |
| Bus bit rate | 5 Mbps |
| Control frequency | 3 kHz |
| Parameter | Value |
|---|---|
| Backlash | <10 arcmin |
| Positioning repeatability | <12 arcmin |
| Absolute positioning accuracy | <15 arcmin |
Planetary joint module rated at 2 N·m and 40 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 2 N·m and 40 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestPlanetary joint module rated at 3.5 N·m and 82 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on request