
HOTPlanetary Joint Module
XTR-J110
Planetary joint module rated at 18 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestEvaluate a higher rated-torque module within the conventional-body range for a mechanically calculated robot joint.
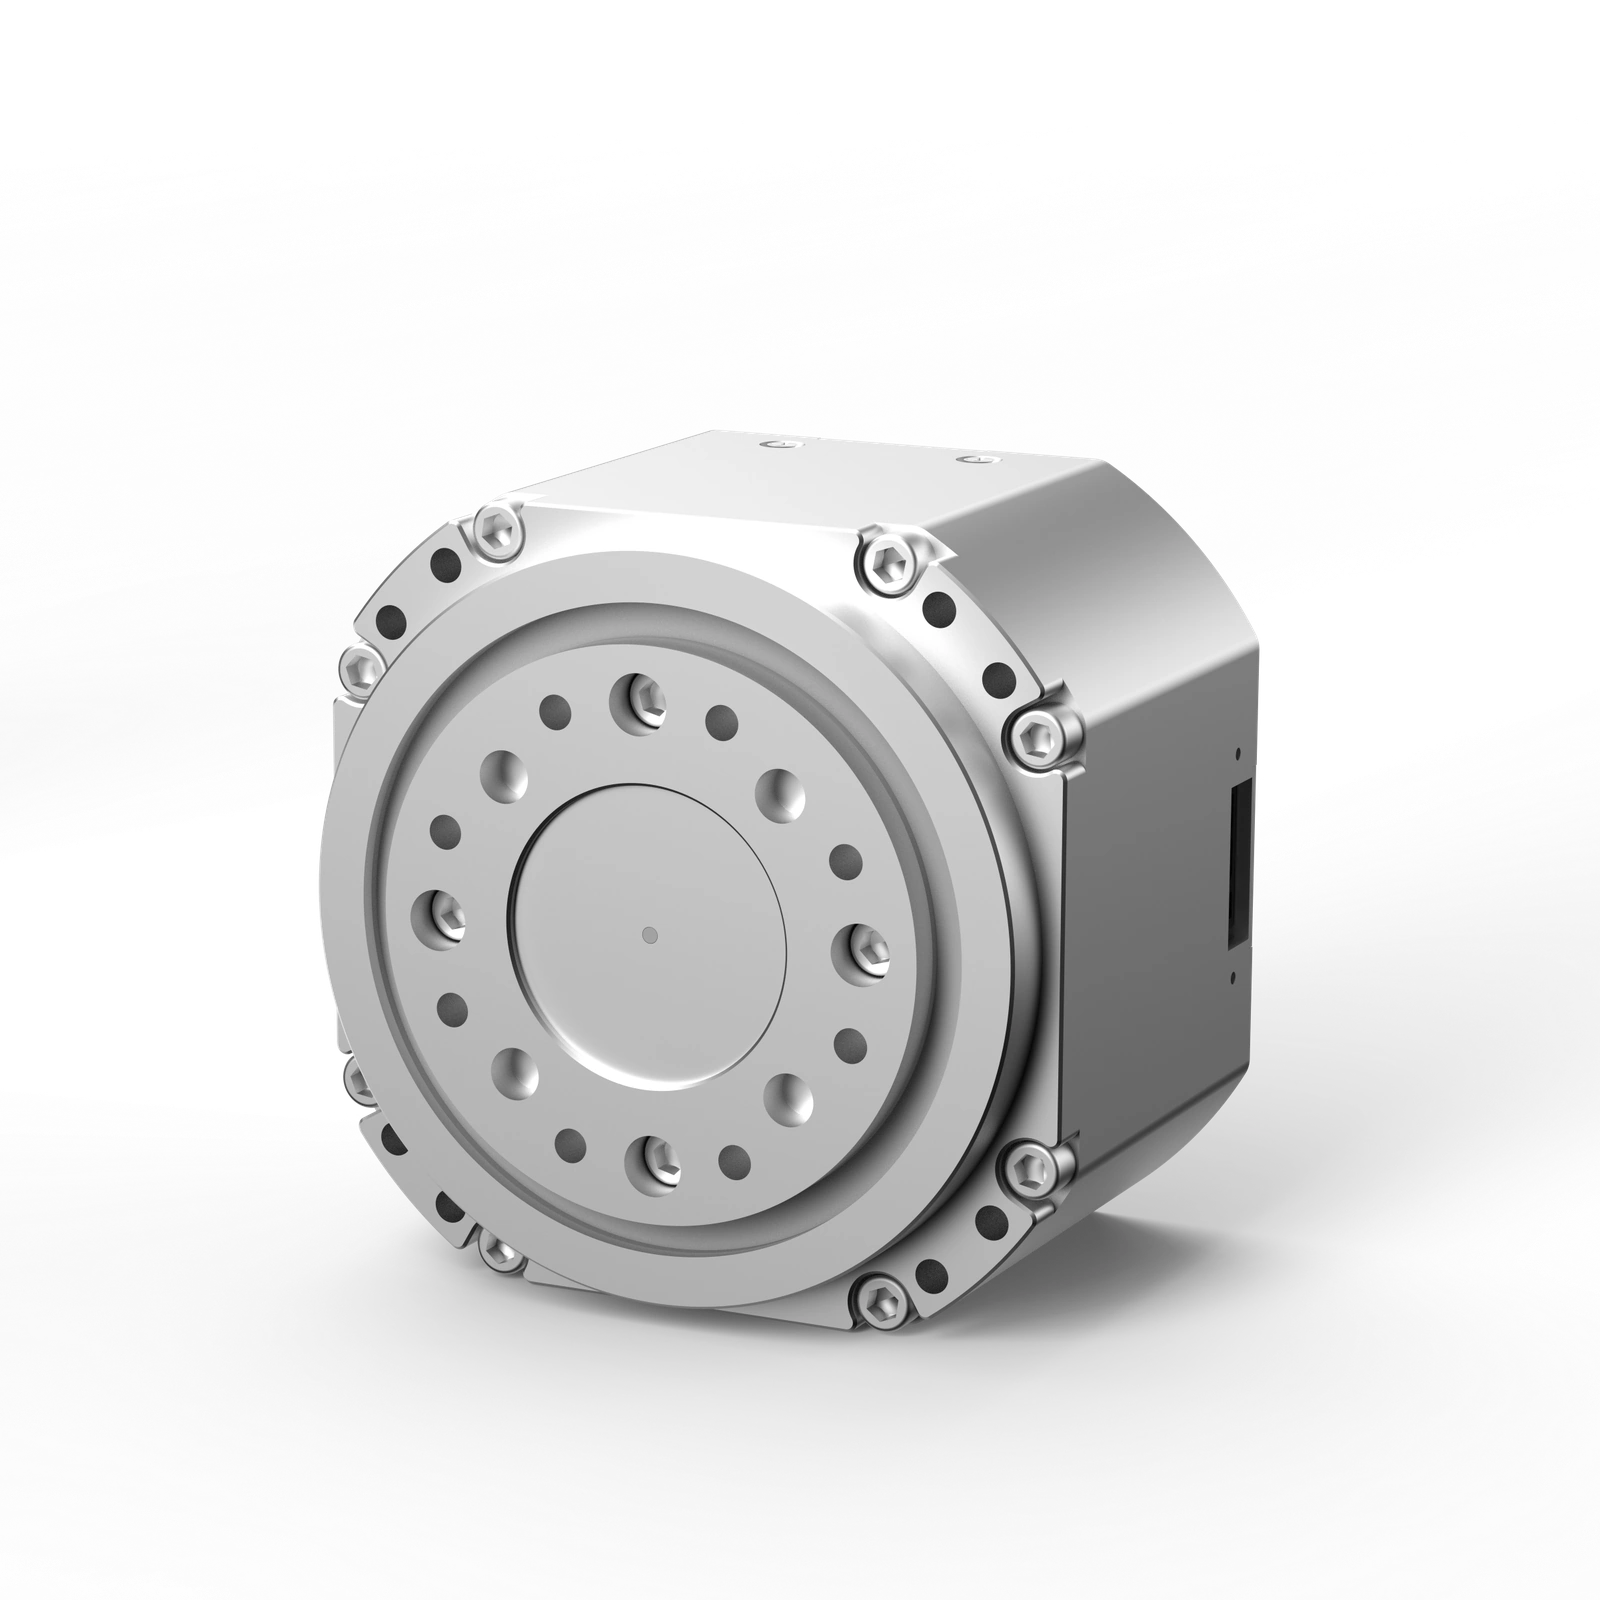
J110 lists 18 N·m rated torque, 50 rpm and a mass of 850 g. Its 60 N·m stall value is distinct from continuous rated output.
Indicative guide prices in USD. Confirm exact configuration and quantity pricing in your inquiry.
Planetary joint module rated at 18 N·m and 50 rpm, with CAN FD / CAN communication.
Guide price · Exact quote on requestDetermine the joint location from system-level loads, inertia and the working cycle. Confirm cooling and support structure; do not size continuous operation from stall torque.
Prepare your requirementsSelect models and quantities, describe your application and prepare a request for configuration-specific or wholesale pricing.