Locomotion & control
- Balance and walking-control experiments
- Gait transitions and motion-policy evaluation
- Simulation-to-hardware development
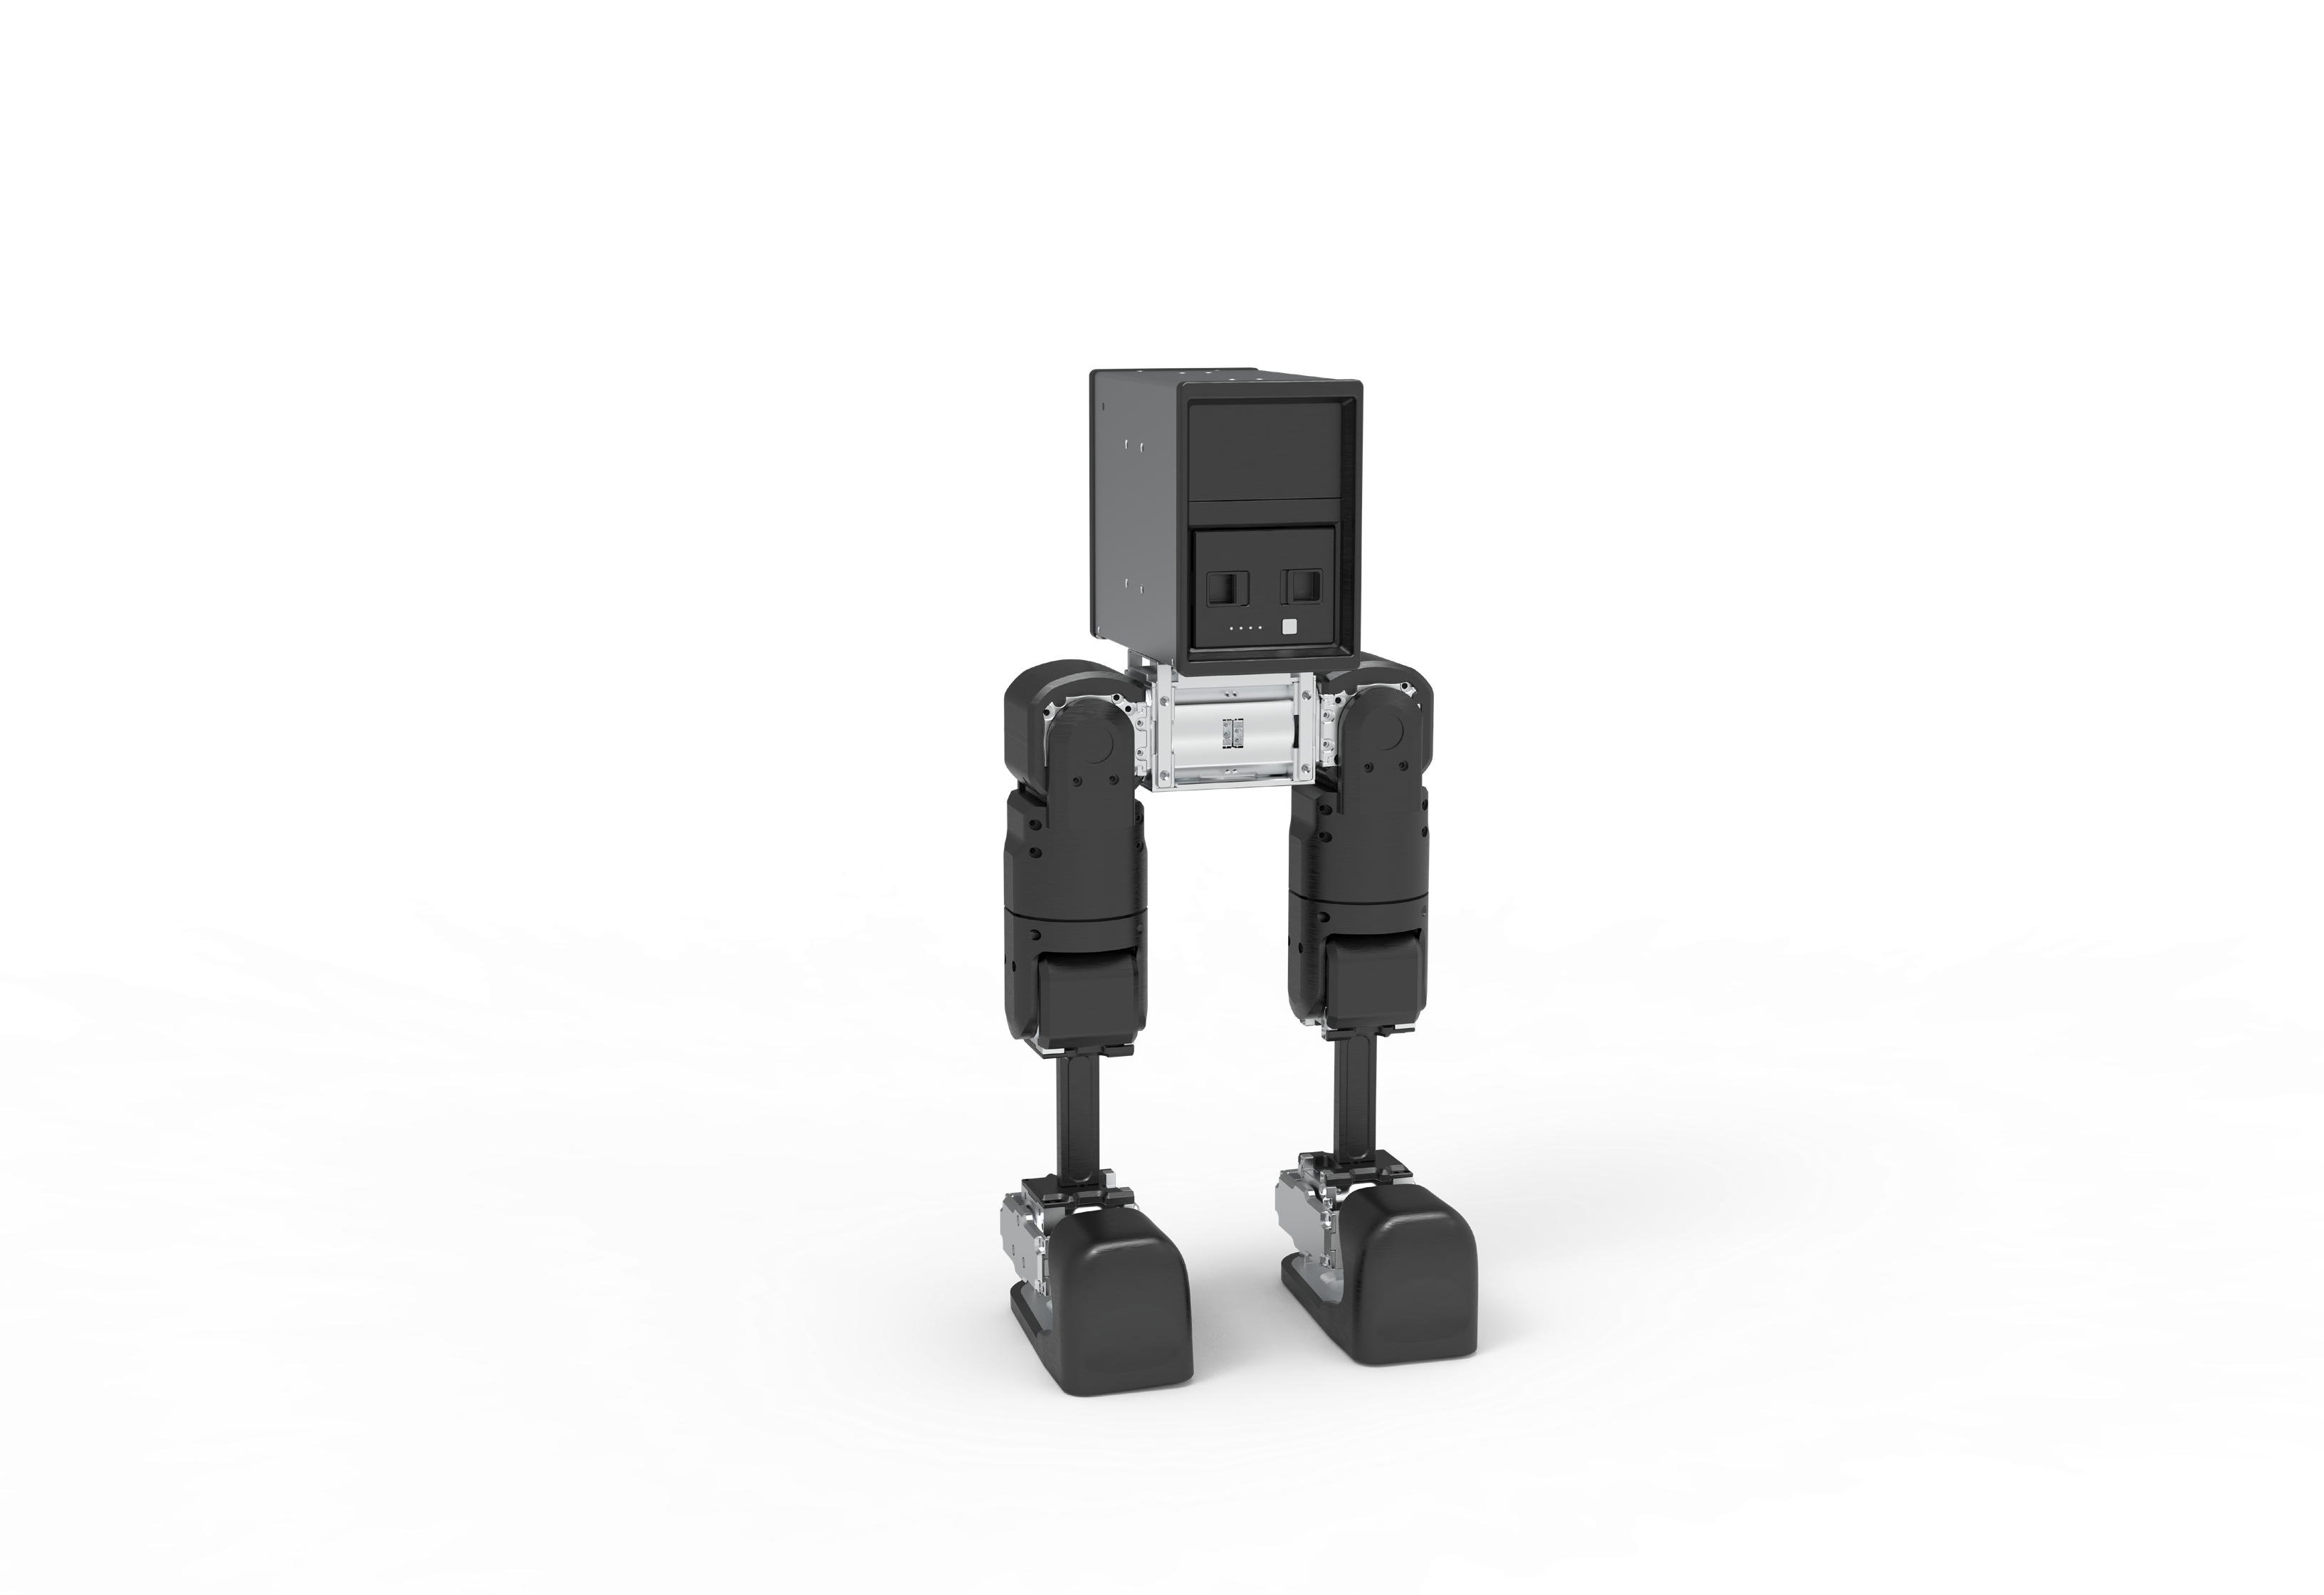
View full-size image ↗ · 3264 × 2240 px
Product image. Confirm the selected configuration before ordering.
Compact 520 mm humanoid with 12 degrees of freedom and a choice of RK3588 or Orin NX compute.
Catalog specifications · page 2Application guidance is based on the listed hardware and development resources. Confirm the software, sensors and integration your project needs.
Check the simulation model, training baseline and deployment interfaces for the supplied revision. Training compute may be separate. Neither H100 configuration lists a depth camera in the catalog.
Confirm teaching examples, course materials, training, spare parts and support separately. Match the lab space, equipment and supervision to the course.
| Parameter | XTR-H100 | XTR-H100-P |
|---|---|---|
| Standing height | 520 mm | 520 mm |
| Weight with battery | 7 kg | 7 kg |
| Degrees of freedom | 12 | 12 |
| Peak joint torque | 16 N·m | 16 N·m |
| Nominal battery voltage | 24 V | 24 V |
| Rated battery capacity | 5,000 mAh | 5,000 mAh |
| Processor | RK3588 | Orin NX |
| High-performance IMU | Included | Included |
| High-performance low-level controller | Included | Included |
| SDK interface | Included | Included |
| Visual navigation SDK | - | - |
| Depth camera | - | - |
| Battery with BMS and charger | Included | Included |
| Remote control | Included | Included |
| Built-in motions | Waist twist, hip twist, splits, lunge | Waist twist, hip twist, splits, lunge |
650 mm humanoid with 22 degrees of freedom, an eight-microphone array and up to 1.1 m/s listed maximum speed.
Guide price · Exact quote on requestLarger 48 V humanoid platform with 36 N·m peak joint torque and up to 25 degrees of freedom in the Pro version.
Guide price · Exact quote on request