
H SERIES
XTR-H100
Compact 520 mm humanoid with 12 degrees of freedom and a choice of RK3588 or Orin NX compute.
Guide price · Exact quote on requestExplore biped balance, gait development and the transition from simulation to physical hardware on a compact robot platform.
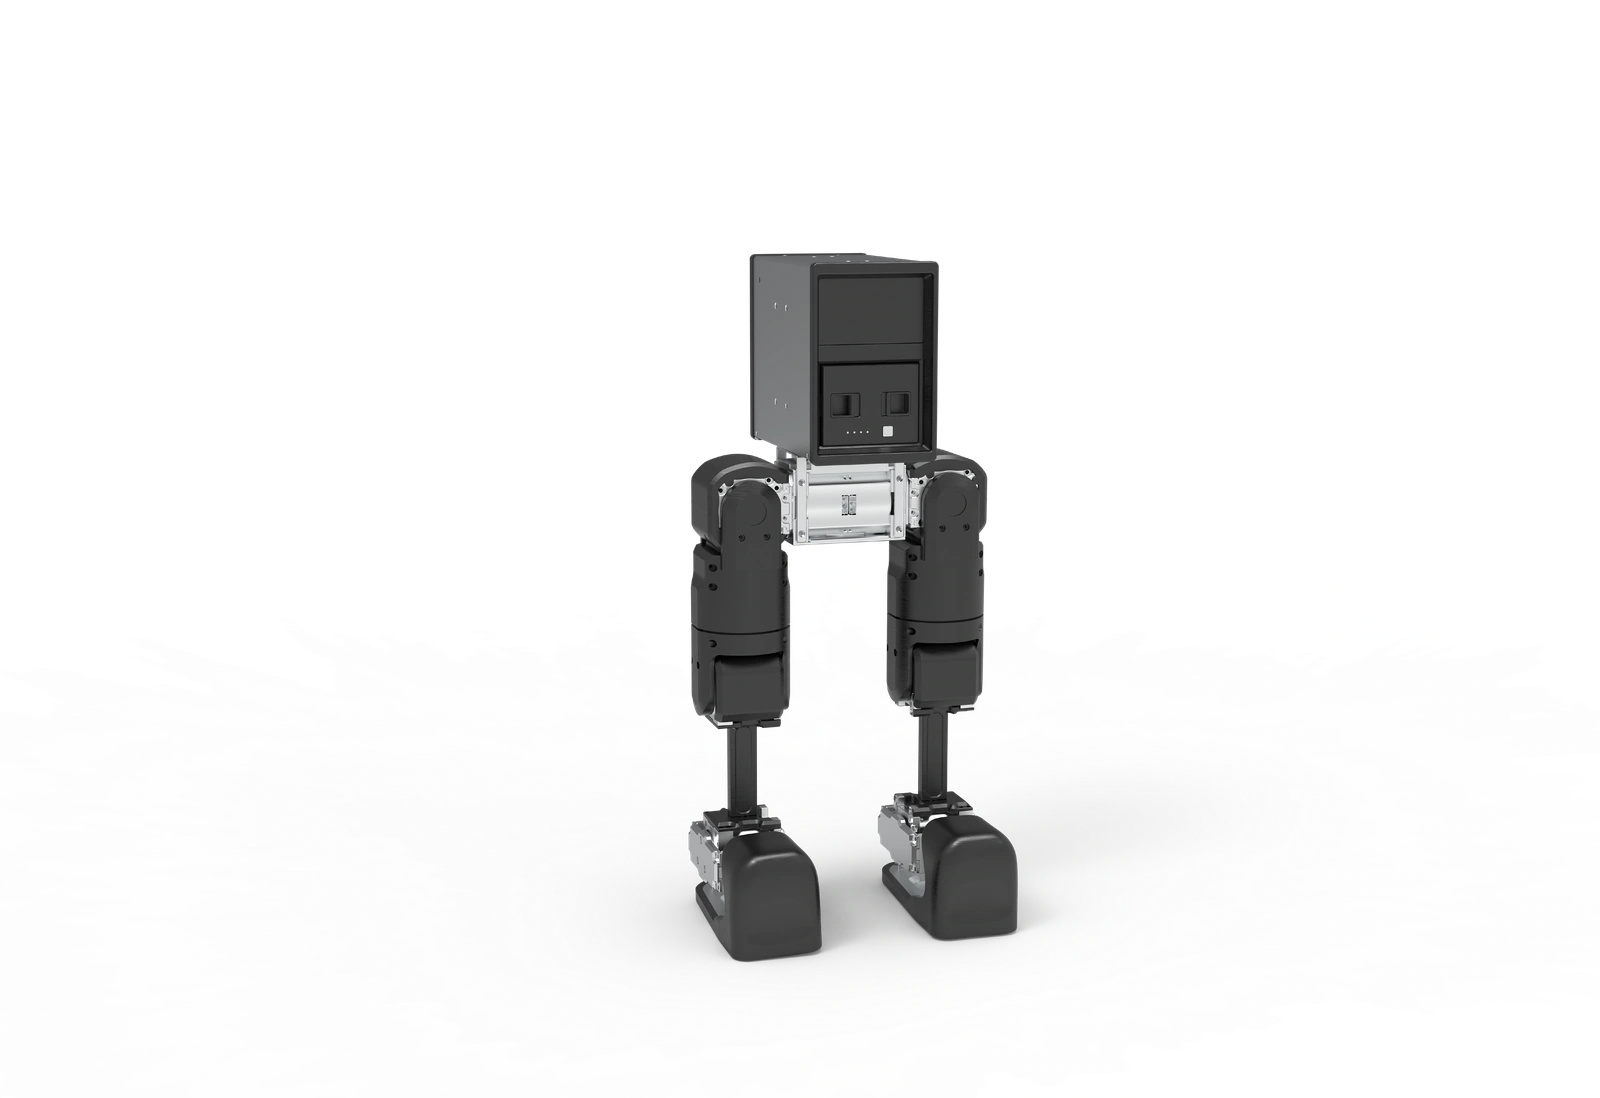
The 520 mm H100 platform provides 12 degrees of freedom, an IMU and an SDK. Choose RK3588 or the H100-P Orin NX configuration to match deployment needs.
Indicative guide prices in USD. Confirm exact configuration and quantity pricing in your inquiry.
Compact 520 mm humanoid with 12 degrees of freedom and a choice of RK3588 or Orin NX compute.
Guide price · Exact quote on requestCheck the simulation model, training baseline and deployment interfaces for the supplied revision. Training compute may be separate. Neither H100 configuration lists a depth camera in the catalog.
Prepare your requirementsSelect models and quantities, describe your application and prepare a request for configuration-specific or wholesale pricing.